
Solution architecture
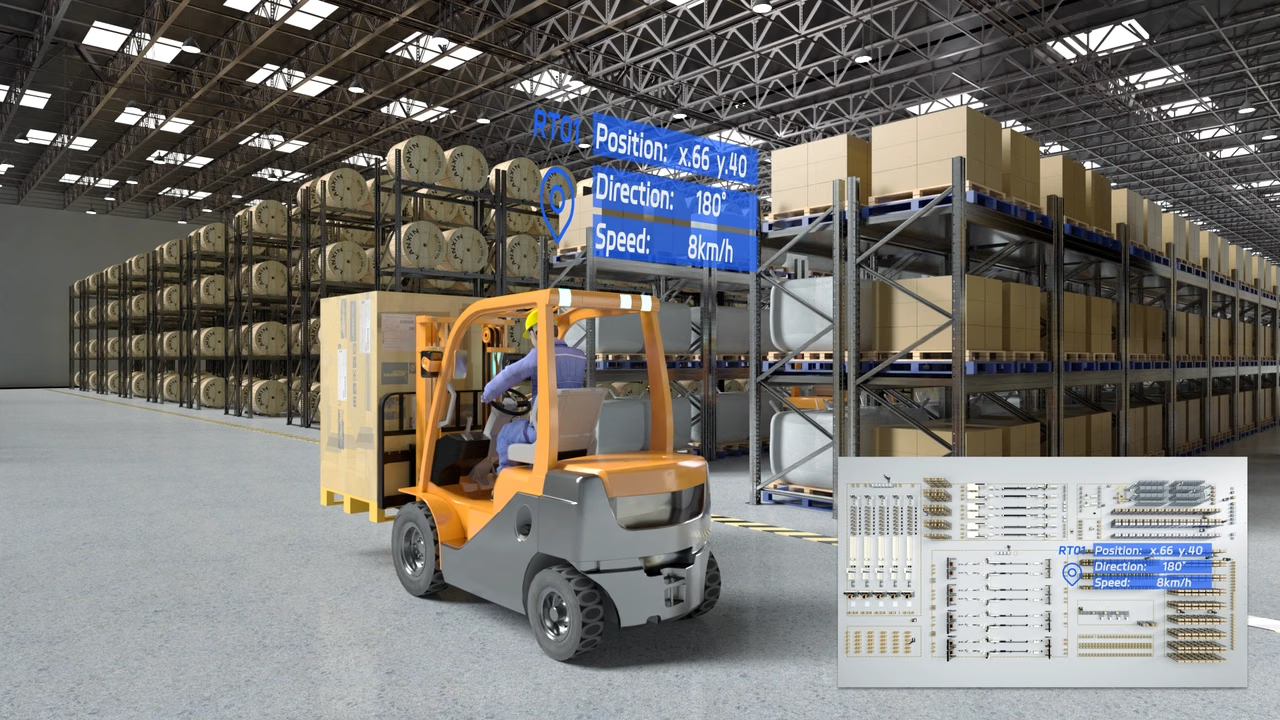
The solution combines a manual-forklift localization system with a storage-location status system. The first provides forklift position and pose; the second provides occupancy and load status. Both data streams can be sent to a higher-level system for task dispatch and load tracking.Manual forklift localization
Mount a 3D vision camera on top of the forklift. The system localizes using natural features on the ceiling and walls, with IMU assistance. Project records report 1–5 cm positioning accuracy; actual accuracy depends on site features, installation, and calibration.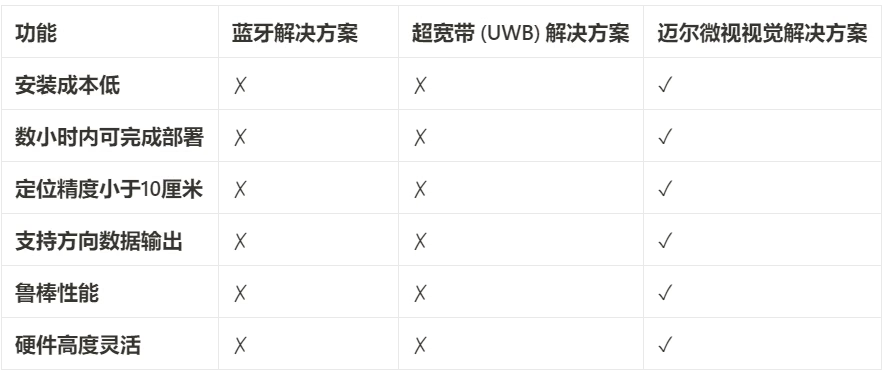
Storage-location status recognition
An RGB-D camera captures 3D and color information to identify whether a location contains a load, how it is placed, and whether occupancy is abnormal. The algorithm can distinguish load categories when required, and camera-side results can be sent to the dispatch system.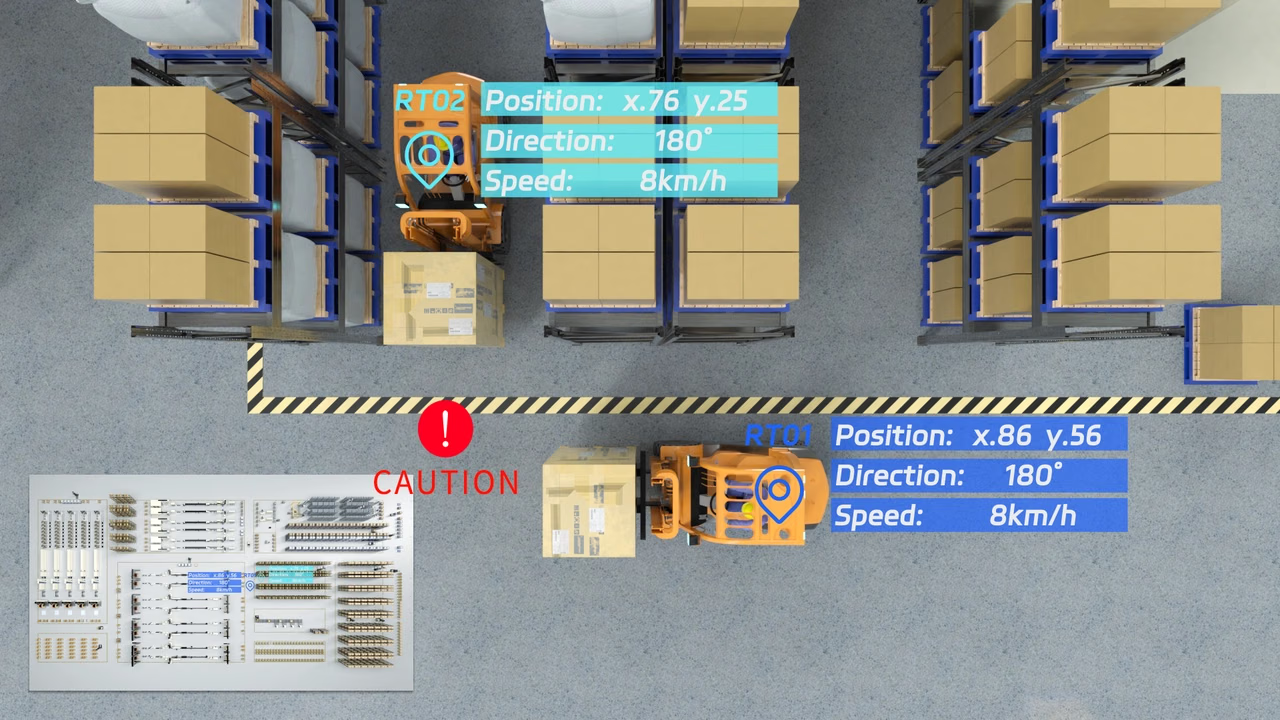
Coordination workflow
- The localization system continuously outputs forklift position and pose.
- The location camera reports occupancy and load status for the target location.
- The higher-level system associates vehicle, load, and location data to confirm pickup and placement tasks and record load positions.
- When location or vehicle status changes, the higher-level system can update task routes and resource allocation.