Obstacle-avoidance parameters
Export
1
Open obstacle-avoidance settings
In Application algorithm, select the obstacle-avoidance algorithm and configure the obstacle-avoidance regions and extrinsics.
2
Send the parameters
In Obstacle avoidance settings, select Send parameters.
3
Locate the file
Open the
params folder in the host application directory, then open the directory for the camera ID. The avoidance file contains the saved parameters.D:\\Program Files\\Lanxin-MRDVS\\Tools\\params
Import
In Obstacle avoidance settings, select Load configuration from file and choose the exported file. Send the configuration, then verify the region in the point-cloud view and output status.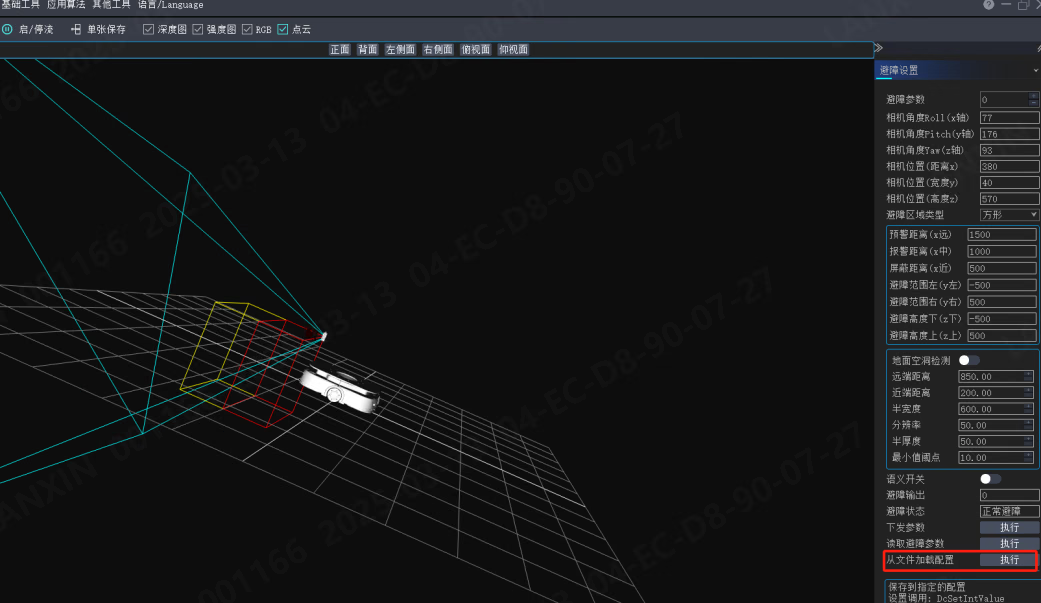
Imaging and filter parameters
Export
- Configure imaging and filter parameters in Basic tools.
- Stop the camera stream. A configuration cannot be saved while streaming.
- In Function settings, select Export configuration to file and create a dedicated folder for the configuration.
Import
In Function settings, select Load configuration from file and choose the exported file. Restart the stream and verify image quality and filtering.PalletPro pallet parameters
PalletPro1.4.6 and later can manage pallet-recognition extrinsics in the active algorithm directory.
Import
1
Open the camera directory
Start PalletPro, select Basic operations → Camera operations → Open directory, and open the algorithm directory currently used by the camera.
2
Replace the parameter file
Copy or drag the pallet-recognition extrinsics into the directory and confirm replacement of the matching file.
3
Calibrate again
After the import, run pallet docking extrinsic calibration again and verify recognition results.
Export
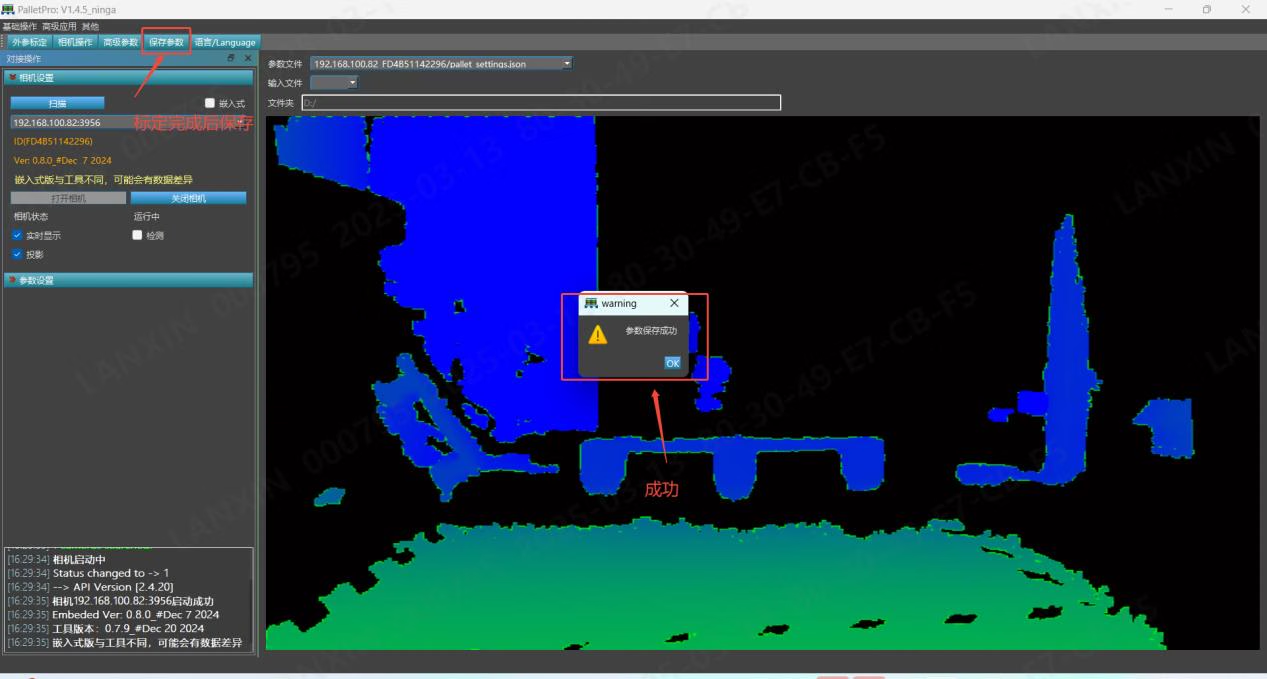
After completing and saving calibration, open the active algorithm directory using the same path and back up the pallet-recognition parameter file.