
Download complete product documentation from the Download center.
Key features
- Close-range iToF depth sensing: Outputs depth data within a 0.05–1 m range.
- Synchronized RGB-D output: Provides depth maps, RGB images, and point clouds with RGB alignment.
- Low-light performance: Active illumination supports targets with low illumination or limited texture.
- GMSL2 transmission: Provides a long-distance, interference-resistant data link for system integration.
Specifications
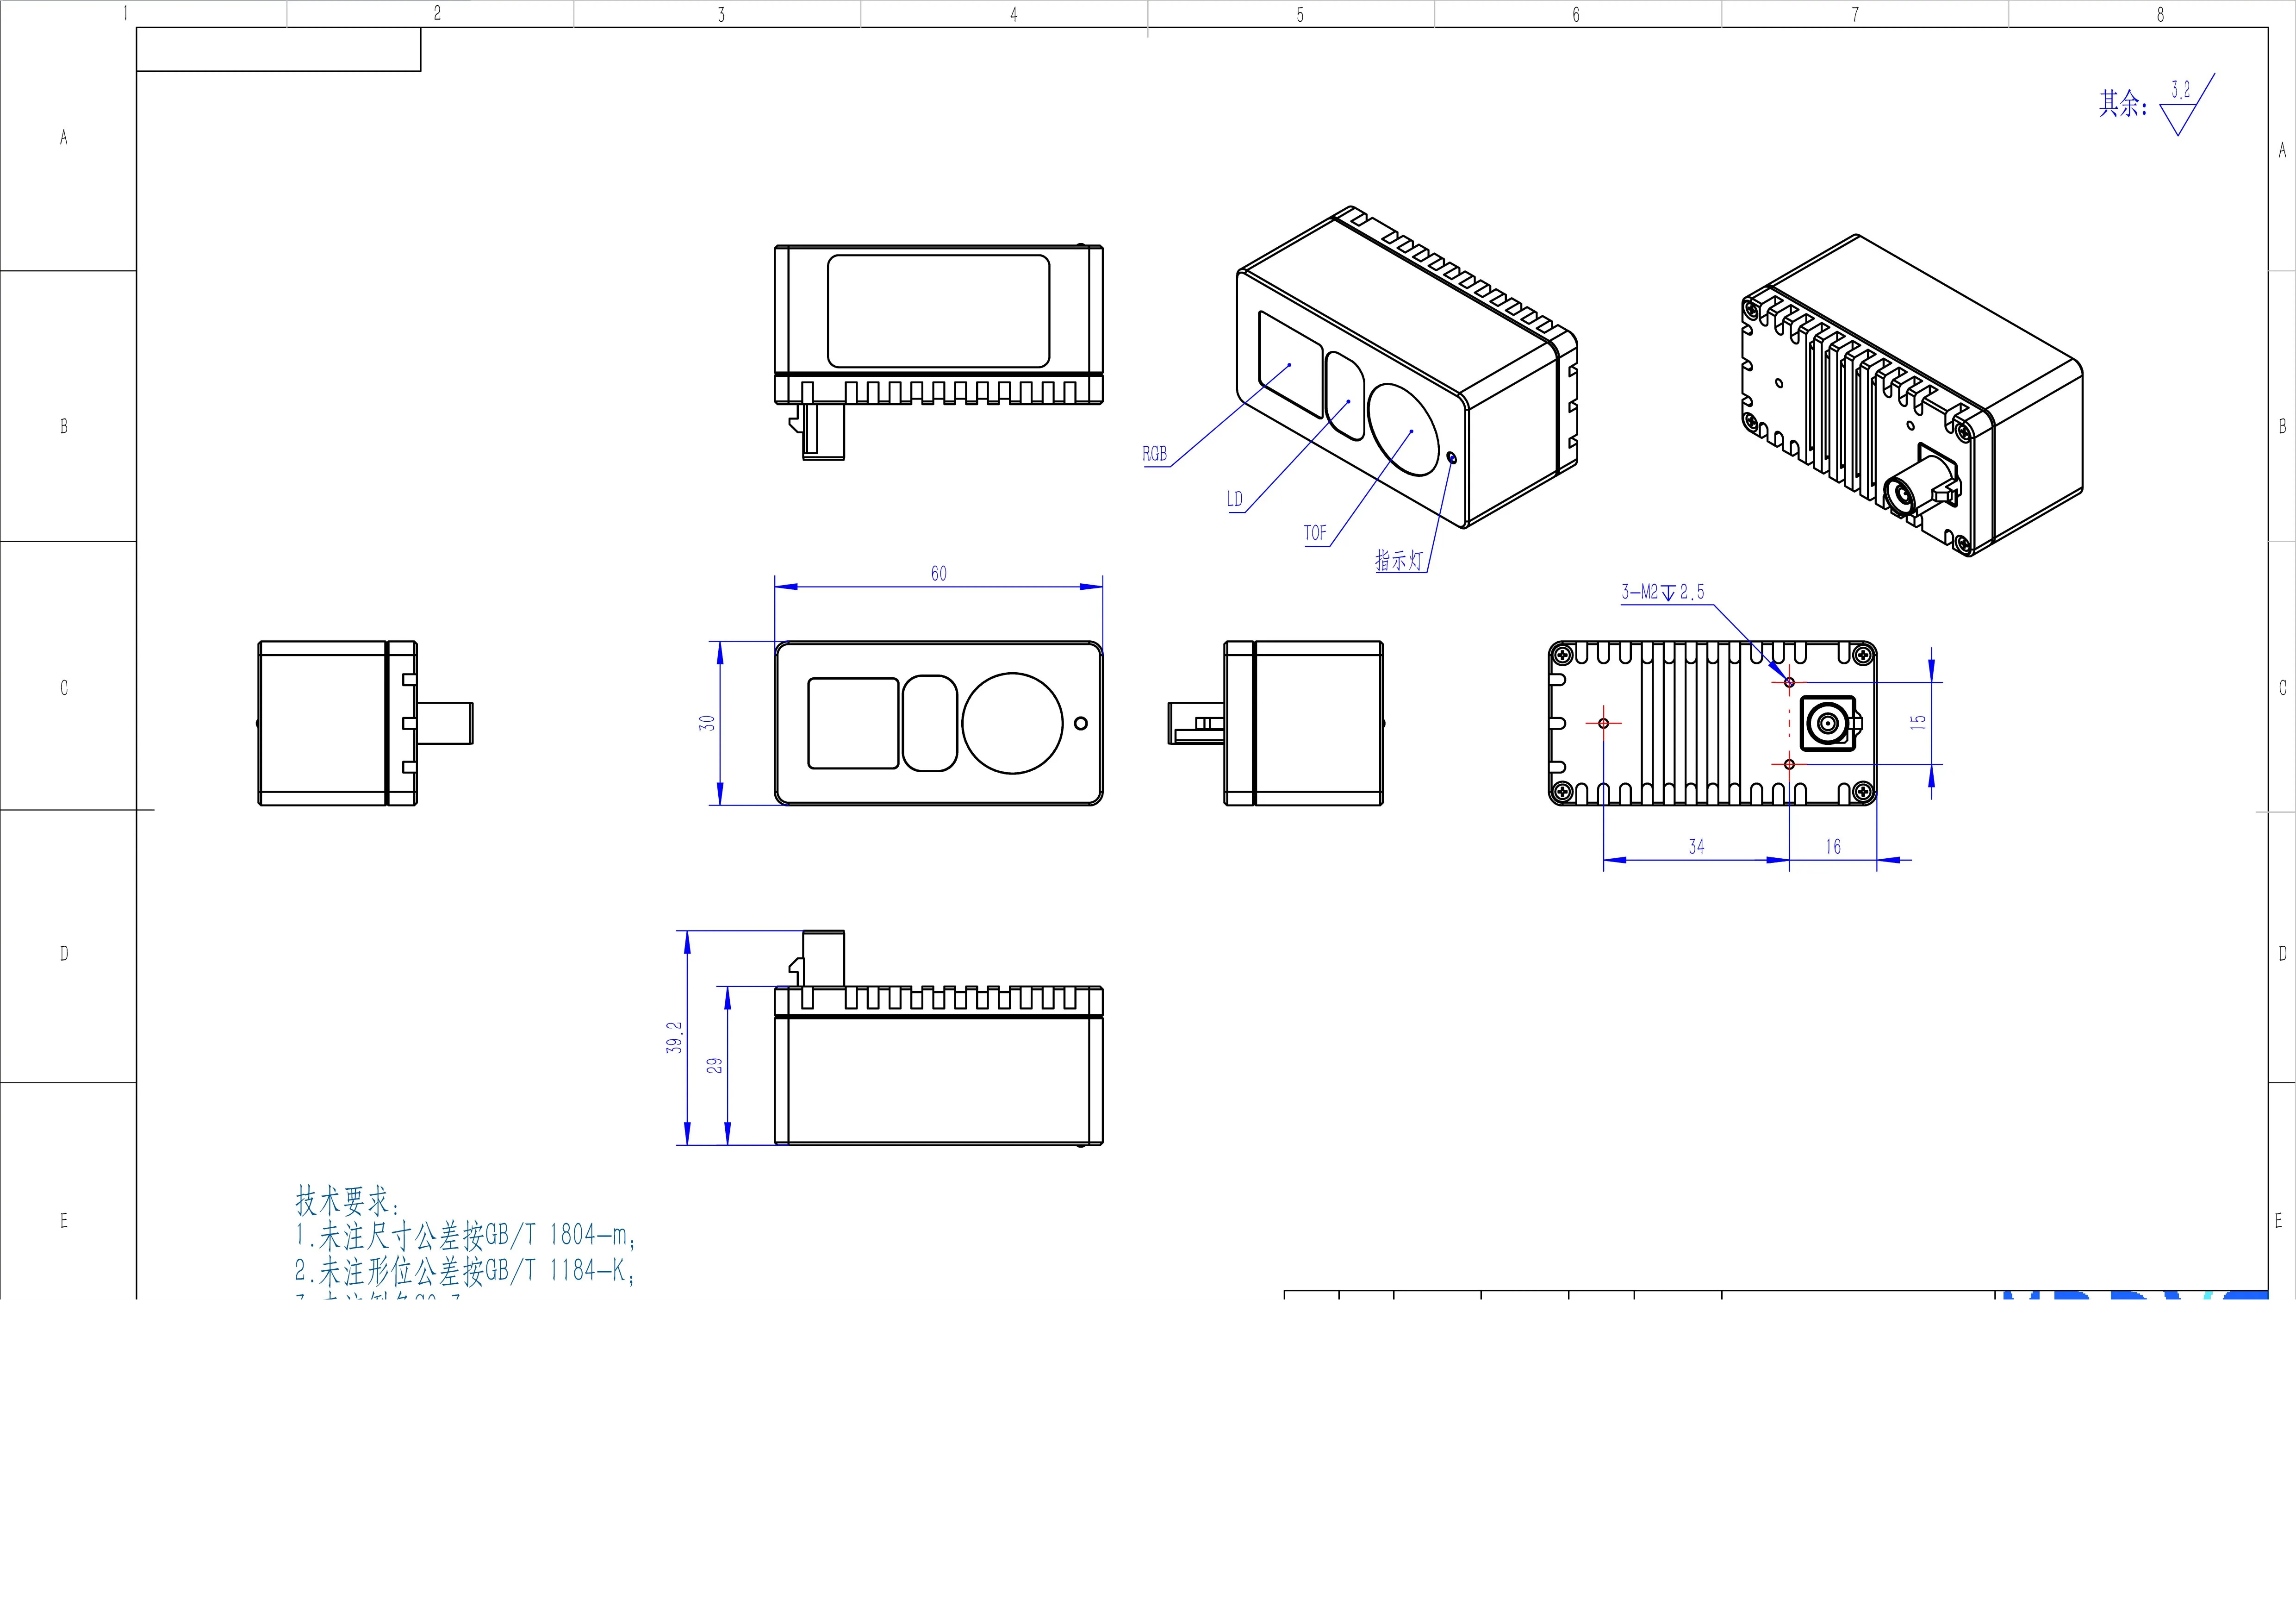
Product dimensions
GMSL2 interface
Serializer configuration
Video stream parameters
FPGA configuration
Start streaming
Image capture requires both hardware frame synchronization and stream control.1
Provide a frame synchronization signal
Configure frame synchronization between MAX96717 and the selected deserializer according to the hardware manuals. MAX96717 MFP0 can be configured as a GPIO trigger output.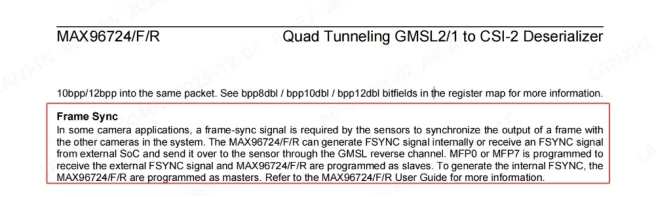
2
Send the stream-start command
Write In this example,
1 to FPGA register 0x2000 to start streaming, or write 0 to stop streaming.0x11 is the FPGA I²C address.