Case study: 3D visual obstacle avoidance for a wheeled humanoid robot
An MRDVS S3 RGB-D ToF camera case study for near-floor obstacle perception on a VersaBot wheeled humanoid robot.
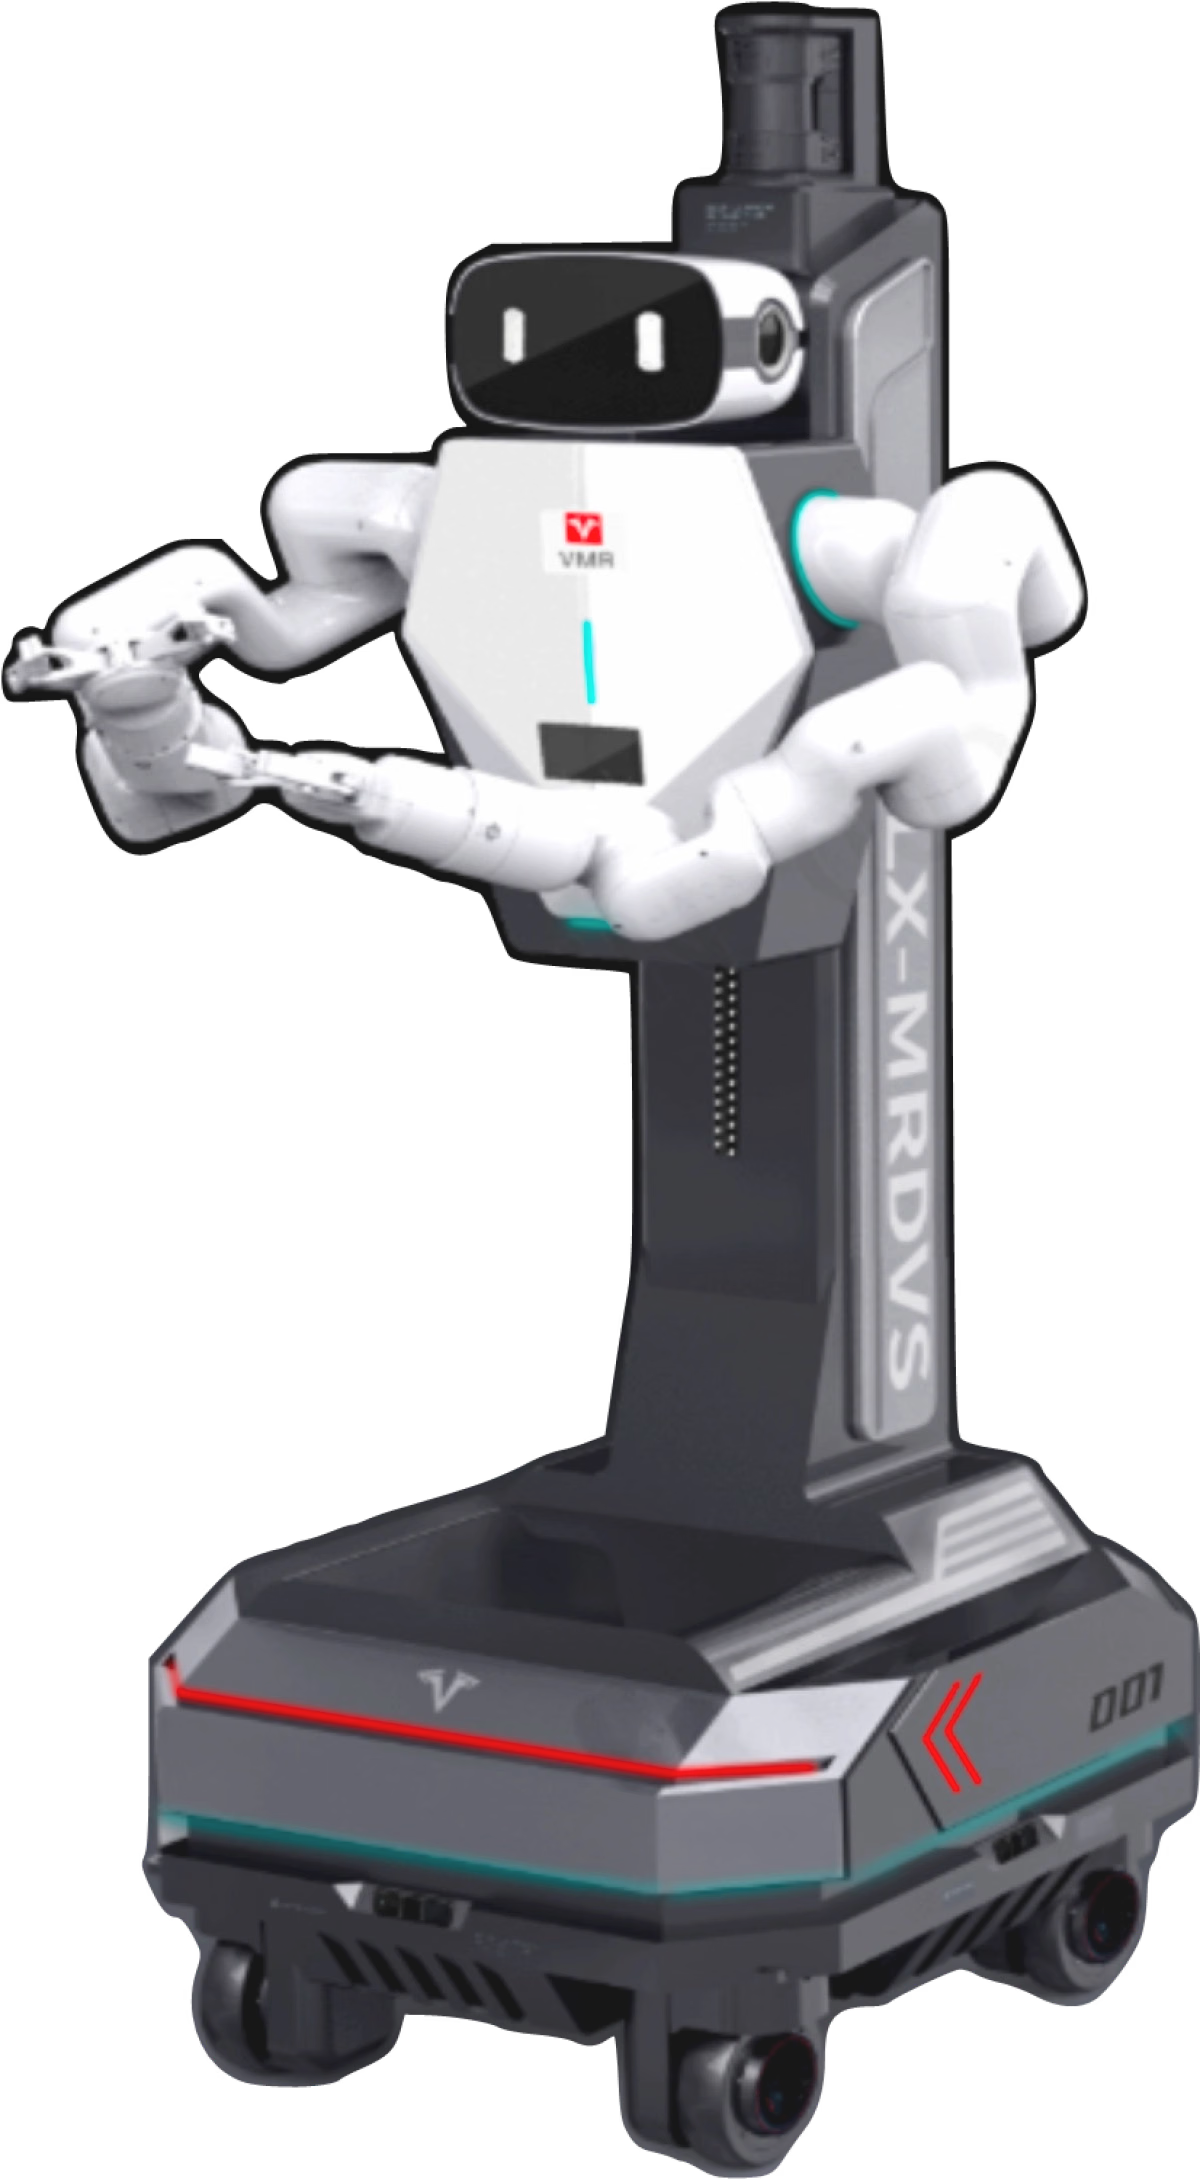
When a wheeled humanoid robot moves through a factory or warehouse, it must cover near-floor and surrounding obstacles. VersaBot mounts an MRDVS S3 RGB-D ToF camera at the bottom of the robot to capture environmental data near its travel path.
The S3 captures RGB images and depth data together, providing distance, color, and texture information. Mounting the camera low on the robot brings near-floor obstacles into the field of view and supplies 3D perception inputs to the higher-level avoidance policy.
The 3D camera is one part of the perception chain. Configure and validate vehicle-level avoidance and safety policies using operating speed, braking capability, blind spots, and an on-site risk assessment.
Was this page helpful?
{"docsConfig":{"theme":"mint","$schema":"https://mintlify.com/docs.json","name":"MRDVS","description":"迈尔微视产品、开发集成、行业解决方案与客户支持文档。","colors":{"primary":"#1248B8","light":"#43A5E5","dark":"#217DB5"},"logo":{"light":"https://mintcdn.com/mrdvs/gEte5Lm3vPtLdk_a/logo/logo.svg?fit=max\u0026auto=format\u0026n=gEte5Lm3vPtLdk_a\u0026q=85\u0026s=1d0001033c0b1f686e1d5e4c6576c469","dark":"https://mintcdn.com/mrdvs/gEte5Lm3vPtLdk_a/logo/logo.svg?fit=max\u0026auto=format\u0026n=gEte5Lm3vPtLdk_a\u0026q=85\u0026s=1d0001033c0b1f686e1d5e4c6576c469"},"favicon":{"light":"https://mintcdn.com/mrdvs/JvNnjyd3Kf1Xtjg2/images/favicon.png?fit=max\u0026auto=format\u0026n=JvNnjyd3Kf1Xtjg2\u0026q=85\u0026s=32919de7e789d7ed8f560b485c05bd4a","dark":"https://mintcdn.com/mrdvs/JvNnjyd3Kf1Xtjg2/images/favicon.png?fit=max\u0026auto=format\u0026n=JvNnjyd3Kf1Xtjg2\u0026q=85\u0026s=32919de7e789d7ed8f560b485c05bd4a"},"appearance":{"default":"light","strict":true},"navbar":{"links":[{"icon":{"style":"brands","name":"github"},"href":"https://github.com/Lanxin-MRDVS","label":"GitHub"},{"icon":"/images/favicon.png","href":"https://www.mrdvs.cn/","label":"MRDVS"}],"primary":{"type":"button","label":"联系我们","href":"https://work.weixin.qq.com/ca/cawcde978188b336f1"}},"footer":{"socials":{"github":"https://github.com/Lanxin-MRDVS/CameraSDK","linkedin":"https://www.linkedin.com/company/mrdvs","youtube":"https://www.youtube.com/@MRDVS-2024","website":"https://www.mrdvs.cn/"},"links":[{"header":"产品","items":[{"label":"S 系列3D相机","href":"https://www.mrdvs.cn/product/3d-obstacle-avoidance-cameras-s-series"},{"label":"M 系列3D相机","href":"https://www.mrdvs.cn/product/m-series"},{"label":"V 系列导航模组","href":"https://www.mrdvs.cn/product/v-series"}]},{"header":"解决方案","items":[{"label":"移动机器人视觉","href":"https://www.mrdvs.cn/solutions/solutions-industrial-mobile-robot"},{"label":"仓储物流自动化","href":"https://www.mrdvs.cn/solutions/solutions-warehouse-visual-perception"},{"label":"无人机视觉感知","href":"https://www.mrdvs.cn/solutions/solutions-drones"}]},{"header":"联系我们","items":[{"label":"关于 MRDVS","href":"/about"},{"label":"售前咨询","href":"https://work.weixin.qq.com/ca/cawcde978188b336f1"},{"label":"电话:400-025-6680","href":"/contact"},{"label":"[email protected]","href":"mailto:[email protected]"}]}]},"seo":{"metatags":{"canonical":"https://docs.mrdvs.com","google-site-verification":"paNq6FdXn6w3vlYqGqsx4YFtZgIyoE54Ya803O0ilNM","baidu-site-verification":"codeva-aVWshvu4wM","msvalidate.01":"79667988DD5B77655E355B82AFD283E3"}},"icons":{"library":"fontawesome"},"styling":{"eyebrows":"section","latex":false},"integrations":{"clarity":{"projectId":"xmhznno359"},"ga4":{"measurementId":"G-0F8Q5CXHX4"}},"errors":{"404":{"redirect":false}},"contextual":{"options":["copy","view","chatgpt","claude"],"display":"header"},"interaction":{"drilldown":false},"navigation":{"languages":[{"language":"zh-CN","default":true,"footer":{"socials":{"github":"https://github.com/Lanxin-MRDVS/CameraSDK","linkedin":"https://www.linkedin.com/company/mrdvs","youtube":"https://www.youtube.com/@MRDVS-2024","website":"https://www.mrdvs.cn/"},"links":[{"header":"产品","items":[{"label":"S 系列3D相机","href":"https://www.mrdvs.cn/product/3d-obstacle-avoidance-cameras-s-series"},{"label":"M 系列3D相机","href":"https://www.mrdvs.cn/product/m-series"},{"label":"V 系列导航模组","href":"https://www.mrdvs.cn/product/v-series"}]},{"header":"解决方案","items":[{"label":"移动机器人视觉","href":"https://www.mrdvs.cn/solutions/solutions-industrial-mobile-robot"},{"label":"仓储物流自动化","href":"https://www.mrdvs.cn/solutions/solutions-warehouse-visual-perception"},{"label":"无人机视觉感知","href":"https://www.mrdvs.cn/solutions/solutions-drones"}]},{"header":"联系我们","items":[{"label":"关于 MRDVS","href":"/about"},{"label":"售前咨询","href":"https://work.weixin.qq.com/ca/cawcde978188b336f1"},{"label":"电话:400-025-6680","href":"/contact"},{"label":"[email protected]","href":"mailto:[email protected]"},{"label":"浙ICP备2023021387号-2","href":"https://beian.miit.gov.cn/"}]}]},"navbar":{"links":[{"icon":{"style":"brands","name":"github"},"href":"https://github.com/Lanxin-MRDVS","label":"GitHub"},{"icon":"/images/favicon.png","href":"https://www.mrdvs.cn/","label":"MRDVS"}],"primary":{"type":"button","label":"联系我们","href":"https://work.weixin.qq.com/ca/cawcde978188b336f1"}},"href":""},{"language":"en","footer":{"socials":{"github":"https://github.com/Lanxin-MRDVS/CameraSDK","linkedin":"https://www.linkedin.com/company/mrdvs","youtube":"https://www.youtube.com/@MRDVS-2024","website":"https://mrdvs.com/"},"links":[{"header":"Products","items":[{"label":"S Series 3D Cameras","href":"https://mrdvs.com/s-series-obstacle-avoidance-robot-cameras"},{"label":"M Series 3D Cameras","href":"https://mrdvs.com/m-series-time-of-flight-camera"},{"label":"V Series Localization","href":"https://mrdvs.com/v2-pro-rtls-slam-solution"}]},{"header":"Solutions","items":[{"label":"Mobile Robot Vision","href":"https://mrdvs.com/humanoids-quadrupeds-robots"},{"label":"Warehouse \u0026 Logistics","href":"https://mrdvs.com/vision-guided-robotics"},{"label":"Lawn Mower Perception","href":"https://mrdvs.com/solid-state-lidar-vision-fusion"}]},{"header":"Contact Us","items":[{"label":"About MRDVS","href":"/en/about"},{"label":"WhatsApp","href":"https://wa.me/8613370882355"},{"label":"[email protected]","href":"mailto:[email protected]"}]}]},"navbar":{"links":[{"icon":{"style":"brands","name":"github"},"href":"https://github.com/Lanxin-MRDVS","label":"GitHub"},{"icon":"/images/favicon.png","href":"https://mrdvs.com/","label":"MRDVS"}],"primary":{"type":"button","label":"Contact Us","href":"/en/contact"}},"href":"en"},{"language":"ja","footer":{"socials":{"github":"https://github.com/Lanxin-MRDVS/CameraSDK","linkedin":"https://www.linkedin.com/company/mrdvs","youtube":"https://www.youtube.com/@MRDVS-2024","website":"https://mrdvs.com/"},"links":[{"header":"製品","items":[{"label":"Sシリーズ3Dカメラ","href":"https://mrdvs.com/s-series-obstacle-avoidance-robot-cameras"},{"label":"Mシリーズ3Dカメラ","href":"https://mrdvs.com/m-series-time-of-flight-camera"},{"label":"Vシリーズローカライゼーション","href":"https://mrdvs.com/v2-pro-rtls-slam-solution"}]},{"header":"ソリューション","items":[{"label":"モバイルロボットビジョン","href":"https://mrdvs.com/humanoids-quadrupeds-robots"},{"label":"倉庫・物流","href":"https://mrdvs.com/vision-guided-robotics"},{"label":"芝刈り機向け認識","href":"https://mrdvs.com/solid-state-lidar-vision-fusion"}]},{"header":"お問い合わせ","items":[{"label":"MRDVSについて","href":"/ja/about"},{"label":"WhatsApp","href":"https://wa.me/8613370882355"},{"label":"[email protected]","href":"mailto:[email protected]"}]}]},"navbar":{"links":[{"icon":{"style":"brands","name":"github"},"href":"https://github.com/Lanxin-MRDVS","label":"GitHub"},{"icon":"/images/favicon.png","href":"https://mrdvs.com/","label":"MRDVS"}],"primary":{"type":"button","label":"お問い合わせ","href":"/ja/contact"}},"href":"ja"},{"language":"ko","footer":{"socials":{"github":"https://github.com/Lanxin-MRDVS/CameraSDK","linkedin":"https://www.linkedin.com/company/mrdvs","youtube":"https://www.youtube.com/@MRDVS-2024","website":"https://mrdvs.com/"},"links":[{"header":"제품","items":[{"label":"S 시리즈 3D 카메라","href":"https://mrdvs.com/s-series-obstacle-avoidance-robot-cameras"},{"label":"M 시리즈 3D 카메라","href":"https://mrdvs.com/m-series-time-of-flight-camera"},{"label":"V 시리즈 위치 추정","href":"https://mrdvs.com/v2-pro-rtls-slam-solution"}]},{"header":"솔루션","items":[{"label":"이동 로봇 비전","href":"https://mrdvs.com/humanoids-quadrupeds-robots"},{"label":"창고 및 물류","href":"https://mrdvs.com/vision-guided-robotics"},{"label":"잔디깎이 로봇 인식","href":"https://mrdvs.com/solid-state-lidar-vision-fusion"}]},{"header":"문의","items":[{"label":"MRDVS 소개","href":"/ko/about"},{"label":"WhatsApp","href":"https://wa.me/8613370882355"},{"label":"[email protected]","href":"mailto:[email protected]"}]}]},"navbar":{"links":[{"icon":{"style":"brands","name":"github"},"href":"https://github.com/Lanxin-MRDVS","label":"GitHub"},{"icon":"/images/favicon.png","href":"https://mrdvs.com/","label":"MRDVS"}],"primary":{"type":"button","label":"문의하기","href":"/ko/contact"}},"href":"ko"},{"language":"vi","footer":{"socials":{"github":"https://github.com/Lanxin-MRDVS/CameraSDK","linkedin":"https://www.linkedin.com/company/mrdvs","youtube":"https://www.youtube.com/@MRDVS-2024","website":"https://mrdvs.com/"},"links":[{"header":"Sản phẩm","items":[{"label":"Camera 3D dòng S","href":"https://mrdvs.com/s-series-obstacle-avoidance-robot-cameras"},{"label":"Camera 3D dòng M","href":"https://mrdvs.com/m-series-time-of-flight-camera"},{"label":"Định vị dòng V","href":"https://mrdvs.com/v2-pro-rtls-slam-solution"}]},{"header":"Giải pháp","items":[{"label":"Thị giác robot di động","href":"https://mrdvs.com/humanoids-quadrupeds-robots"},{"label":"Kho vận \u0026 logistics","href":"https://mrdvs.com/vision-guided-robotics"},{"label":"Nhận thức cho máy cắt cỏ","href":"https://mrdvs.com/solid-state-lidar-vision-fusion"}]},{"header":"Liên hệ","items":[{"label":"Giới thiệu MRDVS","href":"/vi/about"},{"label":"WhatsApp","href":"https://wa.me/8613370882355"},{"label":"[email protected]","href":"mailto:[email protected]"}]}]},"navbar":{"links":[{"icon":{"style":"brands","name":"github"},"href":"https://github.com/Lanxin-MRDVS","label":"GitHub"},{"icon":"/images/favicon.png","href":"https://mrdvs.com/","label":"MRDVS"}],"primary":{"type":"button","label":"Liên hệ","href":"/vi/contact"}},"href":"vi"},{"language":"de","footer":{"socials":{"github":"https://github.com/Lanxin-MRDVS/CameraSDK","linkedin":"https://www.linkedin.com/company/mrdvs","youtube":"https://www.youtube.com/@MRDVS-2024","website":"https://mrdvs.com/"},"links":[{"header":"Produkte","items":[{"label":"3D-Kameras der S-Serie","href":"https://mrdvs.com/s-series-obstacle-avoidance-robot-cameras"},{"label":"3D-Kameras der M-Serie","href":"https://mrdvs.com/m-series-time-of-flight-camera"},{"label":"Lokalisierung der V-Serie","href":"https://mrdvs.com/v2-pro-rtls-slam-solution"}]},{"header":"Lösungen","items":[{"label":"Robotersicht für mobile Roboter","href":"https://mrdvs.com/humanoids-quadrupeds-robots"},{"label":"Lager und Logistik","href":"https://mrdvs.com/vision-guided-robotics"},{"label":"Wahrnehmung für Rasenmäher","href":"https://mrdvs.com/solid-state-lidar-vision-fusion"}]},{"header":"Kontakt","items":[{"label":"Über MRDVS","href":"/de/about"},{"label":"WhatsApp","href":"https://wa.me/8613370882355"},{"label":"[email protected]","href":"mailto:[email protected]"}]}]},"navbar":{"links":[{"icon":{"style":"brands","name":"github"},"href":"https://github.com/Lanxin-MRDVS","label":"GitHub"},{"icon":"/images/favicon.png","href":"https://mrdvs.com/","label":"MRDVS"}],"primary":{"type":"button","label":"Kontakt","href":"/de/contact"}},"href":"de"},{"language":"it","footer":{"socials":{"github":"https://github.com/Lanxin-MRDVS/CameraSDK","linkedin":"https://www.linkedin.com/company/mrdvs","youtube":"https://www.youtube.com/@MRDVS-2024","website":"https://mrdvs.com/"},"links":[{"header":"Prodotti","items":[{"label":"Telecamere 3D serie S","href":"https://mrdvs.com/s-series-obstacle-avoidance-robot-cameras"},{"label":"Telecamere 3D serie M","href":"https://mrdvs.com/m-series-time-of-flight-camera"},{"label":"Localizzazione serie V","href":"https://mrdvs.com/v2-pro-rtls-slam-solution"}]},{"header":"Soluzioni","items":[{"label":"Visione per robot mobili","href":"https://mrdvs.com/humanoids-quadrupeds-robots"},{"label":"Magazzino e logistica","href":"https://mrdvs.com/vision-guided-robotics"},{"label":"Percezione per rasaerba","href":"https://mrdvs.com/solid-state-lidar-vision-fusion"}]},{"header":"Contatti","items":[{"label":"Informazioni su MRDVS","href":"/it/about"},{"label":"WhatsApp","href":"https://wa.me/8613370882355"},{"label":"[email protected]","href":"mailto:[email protected]"}]}]},"navbar":{"links":[{"icon":{"style":"brands","name":"github"},"href":"https://github.com/Lanxin-MRDVS","label":"GitHub"},{"icon":"/images/favicon.png","href":"https://mrdvs.com/","label":"MRDVS"}],"primary":{"type":"button","label":"Contatti","href":"/it/contact"}},"href":"it"},{"language":"es","footer":{"socials":{"github":"https://github.com/Lanxin-MRDVS/CameraSDK","linkedin":"https://www.linkedin.com/company/mrdvs","youtube":"https://www.youtube.com/@MRDVS-2024","website":"https://mrdvs.com/"},"links":[{"header":"Productos","items":[{"label":"Cámaras 3D de la serie S","href":"https://mrdvs.com/s-series-obstacle-avoidance-robot-cameras"},{"label":"Cámaras 3D de la serie M","href":"https://mrdvs.com/m-series-time-of-flight-camera"},{"label":"Localización de la serie V","href":"https://mrdvs.com/v2-pro-rtls-slam-solution"}]},{"header":"Soluciones","items":[{"label":"Visión para robots móviles","href":"https://mrdvs.com/humanoids-quadrupeds-robots"},{"label":"Almacén y logística","href":"https://mrdvs.com/vision-guided-robotics"},{"label":"Percepción para cortacéspedes","href":"https://mrdvs.com/solid-state-lidar-vision-fusion"}]},{"header":"Contacto","items":[{"label":"Acerca de MRDVS","href":"/es/about"},{"label":"WhatsApp","href":"https://wa.me/8613370882355"},{"label":"[email protected]","href":"mailto:[email protected]"}]}]},"navbar":{"links":[{"icon":{"style":"brands","name":"github"},"href":"https://github.com/Lanxin-MRDVS","label":"GitHub"},{"icon":"/images/favicon.png","href":"https://mrdvs.com/","label":"MRDVS"}],"primary":{"type":"button","label":"Contacto","href":"/es/contact"}},"href":"es"},{"language":"ru","footer":{"socials":{"github":"https://github.com/Lanxin-MRDVS/CameraSDK","linkedin":"https://www.linkedin.com/company/mrdvs","youtube":"https://www.youtube.com/@MRDVS-2024","website":"https://mrdvs.com/"},"links":[{"header":"Продукты","items":[{"label":"3D-камеры серии S","href":"https://mrdvs.com/s-series-obstacle-avoidance-robot-cameras"},{"label":"3D-камеры серии M","href":"https://mrdvs.com/m-series-time-of-flight-camera"},{"label":"Локализация серии V","href":"https://mrdvs.com/v2-pro-rtls-slam-solution"}]},{"header":"Решения","items":[{"label":"Зрение мобильных роботов","href":"https://mrdvs.com/humanoids-quadrupeds-robots"},{"label":"Склад и логистика","href":"https://mrdvs.com/vision-guided-robotics"},{"label":"Восприятие для газонокосилок","href":"https://mrdvs.com/solid-state-lidar-vision-fusion"}]},{"header":"Связаться с нами","items":[{"label":"О MRDVS","href":"/ru/about"},{"label":"WhatsApp","href":"https://wa.me/8613370882355"},{"label":"[email protected]","href":"mailto:[email protected]"}]}]},"navbar":{"links":[{"icon":{"style":"brands","name":"github"},"href":"https://github.com/Lanxin-MRDVS","label":"GitHub"},{"icon":"/images/favicon.png","href":"https://mrdvs.com/","label":"MRDVS"}],"primary":{"type":"button","label":"Связаться с нами","href":"/ru/contact"}},"href":"ru"}]}},"deployment":{"deploymentMetadataValue":{"subdomain":"mrdvs","hasAudioNarration":false,"actualSubdomain":"mrdvs","customDomains":["docs.mrdvs.com"],"gitSource":{"type":"github","owner":"lanxin-mrdvs","repo":"mintlify_docs","deployBranch":"main","contentDirectory":"","isPrivate":true,"mountPath":"","label":""},"chroma":{"collectionId":"ac0a5eca-ccf5-4877-b375-714079183569","liveDeploymentHistoryId":"6adb039170fea1df2fc69394","schemaVersion":"v3","latestBuiltDeploymentHistoryId":"6adb039170fea1df2fc69394"},"feedback":{"issues":false,"thumbs":true,"edits":false,"agentFeedback":true},"entitlements":{},"buildId":"6adb039170fea1df2fc69394","clientVersion":"0.0.3965","searchFilterCounts":[{"language":"zh-CN","tag":"工业解决方案","count":22},{"language":"de","tag":"Industrielle Lösungen","count":22},{"language":"en","tag":"Industrial solutions","count":22},{"language":"es","tag":"Soluciones industriales","count":22},{"language":"it","tag":"Soluzioni industriali","count":22},{"language":"ja","tag":"産業向けソリューション","count":22},{"language":"ko","tag":"산업 솔루션","count":22},{"language":"ru","tag":"Промышленные решения","count":22},{"language":"vi","tag":"Giải pháp công nghiệp","count":22},{"language":"zh-CN","tag":"开发者中心","count":13},{"language":"zh-CN","tag":"解决方案与案例","count":13},{"language":"de","tag":"Entwickler","count":13},{"language":"de","tag":"Lösungen und Praxisbeispiele","count":13},{"language":"en","tag":"Developers","count":13},{"language":"en","tag":"Solutions and case studies","count":13},{"language":"es","tag":"Desarrolladores","count":13},{"language":"es","tag":"Soluciones y casos de uso","count":13},{"language":"it","tag":"Sviluppatori","count":13},{"language":"it","tag":"Soluzioni e casi applicativi","count":13},{"language":"ja","tag":"開発者向け","count":13},{"language":"ja","tag":"ソリューション・導入事例","count":13},{"language":"ko","tag":"개발자 센터","count":13},{"language":"ko","tag":"솔루션 및 적용 사례","count":13},{"language":"ru","tag":"Разработчикам","count":13},{"language":"ru","tag":"Решения и примеры внедрения","count":13},{"language":"vi","tag":"Nhà phát triển","count":13},{"language":"vi","tag":"Giải pháp và dự án thực tế","count":13},{"language":"zh-CN","tag":"支持与下载","count":11},{"language":"de","tag":"Support und Downloads","count":11},{"language":"en","tag":"Support and downloads","count":11},{"language":"es","tag":"Soporte y descargas","count":11},{"language":"it","tag":"Supporto e download","count":11},{"language":"ja","tag":"サポート・ダウンロード","count":11},{"language":"ko","tag":"지원 및 다운로드","count":11},{"language":"ru","tag":"Поддержка и загрузки","count":11},{"language":"vi","tag":"Hỗ trợ và tải xuống","count":11},{"language":"zh-CN","tag":"视觉硬件产品","count":10},{"language":"de","tag":"Vision-Hardware","count":10},{"language":"en","tag":"Vision hardware","count":10},{"language":"es","tag":"Hardware de visión","count":10},{"language":"it","tag":"Hardware di visione","count":10},{"language":"ja","tag":"ビジョンハードウェア","count":10},{"language":"ko","tag":"비전 하드웨어","count":10},{"language":"ru","tag":"Оборудование машинного зрения","count":10},{"language":"vi","tag":"Phần cứng thị giác","count":10},{"language":"zh-CN","tag":"智能仓储与搬运","count":8},{"language":"de","tag":"Lagerautomatisierung und Materialtransport","count":8},{"language":"en","tag":"Warehouse automation and handling","count":8},{"language":"es","tag":"Automatización de almacenes y manipulación","count":8},{"language":"it","tag":"Automazione di magazzino e movimentazione","count":8},{"language":"ja","tag":"倉庫自動化・搬送","count":8},{"language":"ko","tag":"창고 자동화 및 물류 이송","count":8},{"language":"ru","tag":"Автоматизация складов и перемещение грузов","count":8},{"language":"vi","tag":"Tự động hóa kho và vận chuyển hàng","count":8},{"language":"zh-CN","tag":"仓储物流","count":6},{"language":"de","tag":"Lager und Logistik","count":6},{"language":"en","tag":"Warehouse and logistics","count":6},{"language":"es","tag":"Almacén y logística","count":6},{"language":"it","tag":"Magazzino e logistica","count":6},{"language":"ja","tag":"倉庫・物流","count":6},{"language":"ko","tag":"창고 및 물류","count":6},{"language":"ru","tag":"Склад и логистика","count":6},{"language":"vi","tag":"Kho vận","count":6},{"language":"zh-CN","tag":"概览","count":5},{"language":"zh-CN","tag":"S 系列环境感知 3D 相机","count":5},{"language":"zh-CN","tag":"下载中心","count":5},{"language":"de","tag":"Überblick","count":5},{"language":"de","tag":"S-Serie – 3D-Kameras zur Umfelderfassung","count":5},{"language":"de","tag":"Downloads","count":5},{"language":"en","tag":"Overview","count":5},{"language":"en","tag":"S Series 3D perception cameras","count":5},{"language":"en","tag":"Downloads","count":5},{"language":"es","tag":"Descripción general","count":5},{"language":"es","tag":"Serie S – cámaras 3D de percepción del entorno","count":5},{"language":"es","tag":"Descargas","count":5},{"language":"it","tag":"Panoramica","count":5},{"language":"it","tag":"Serie S – telecamere 3D per la percezione ambientale","count":5},{"language":"it","tag":"Download","count":5},{"language":"ja","tag":"概要","count":5},{"language":"ja","tag":"Sシリーズ 環境認識3Dカメラ","count":5},{"language":"ja","tag":"ダウンロード","count":5},{"language":"ko","tag":"개요","count":5},{"language":"ko","tag":"S 시리즈 환경 인식 3D 카메라","count":5},{"language":"ko","tag":"다운로드","count":5},{"language":"ru","tag":"Обзор","count":5},{"language":"ru","tag":"Серия S — 3D-камеры восприятия среды","count":5},{"language":"ru","tag":"Загрузки","count":5},{"language":"vi","tag":"Tổng quan","count":5},{"language":"vi","tag":"Camera 3D nhận biết môi trường dòng S","count":5},{"language":"vi","tag":"Tải xuống","count":5}]},"assistantConfig":{"enableAskAiButton":false,"enableStarterQuestions":false,"enableContextualStarterQuestions":false,"enableAskAiSearchBar":true},"hasChatPermissions":false,"hasWebMcpPermissions":false,"toggles":[{"name":"kill-isr","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"agent-mintlify-slack","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"editor-v7-file-tree","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"agent-integrations-settings","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"automations-pr-grouping","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"custom-prefix","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"analytics-v7","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"user-flows-analytics","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"no-publish-flow","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"workos-onboarding","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"llms-txt-v2","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"pause-universal-search-reconcile","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"snapshot-serving-live","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"stripTemperatureMiddleware","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"per-site-search-delta","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"support-platform-pylon-zendesk","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"snapshot-serving","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"instant-rollback","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"granular-notifications-server","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"granular-notifications","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"editor-private-page-search","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"automations-fable","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"fixed-ai-action-pricing","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"automation-resolve-merge-conflict","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"scoped-publishing","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"mintql","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"page-level-analytics","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"editor-version-history-v2","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"editor-nav-generations","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"billing-page-v2","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"workspace-projects","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"assistant-v5","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"byok-sep-25","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"fork-pr-previews","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"revalidation-jwt","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"vite-origin","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"editor-agent-model-picker","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"billing-updated-9-15","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"hobby-abuse-scan","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false},{"name":"dashboard-inbox","enabled":true,"variant":{"name":"disabled","enabled":false,"feature_enabled":true},"impressionData":false}],"isAtlas":false,"googleFontsInlined":false},"customCss":[{"filePath":"assets/styles.css","content":"#localization-select-trigger::before{background-color:currentColor;content:\"\";flex:0 0 .875rem;height:.875rem;margin-right:.125rem;-webkit-mask:url(https://d3gk2c5xim1je2.cloudfront.net/fontawesome/v7.2.0/solid/language.svg) center/contain no-repeat;mask:url(https://d3gk2c5xim1je2.cloudfront.net/fontawesome/v7.2.0/solid/language.svg) center/contain no-repeat;width:.875rem}#ask-assistant-code-block-button,#assistant-entry,#assistant-entry-mobile,#chat-assistant-sheet{display:none!important}"},{"filePath":"style.css","content":".nav-tag-pill-text[data-nav-tag]{display:inline-flex;align-items:center;font-size:.8125rem!important;font-weight:500!important;line-height:1.35!important;padding:.125rem .375rem!important;border-radius:.375rem!important;white-space:nowrap}#sidebar .nav-tag-pill,#sidebar [data-nav-tag]{border-width:0!important;border-style:none!important;outline:0!important;box-shadow:none!important}.mrdvs-discontinued,[data-nav-tag=已停产],[data-nav-tag=新品]{color:#b91c1c!important;background-color:#fef2f2!important;border:0!important}.dark .mrdvs-discontinued,.dark [data-nav-tag=已停产]{color:#fca5a5!important;background-color:#450a0a!important}[data-nav-tag=新品]{color:#854d0e!important;background-color:#fef9c3!important}.dark [data-nav-tag=新品]{color:#fde047!important;background-color:#422006!important}.mrdvs-icp-source{display:none!important}.mrdvs-icp{width:100%;grid-column:1/-1;flex-basis:100%;padding:1.25rem 0;text-align:center;font-size:.8125rem;line-height:1.8;color:#525252}.mrdvs-icp a{text-decoration:underline;text-underline-offset:3px}.dark .mrdvs-icp{color:#d4d4d4}[data-nav-tag=Discontinued]{color:#b91c1c!important;background-color:#fef2f2!important;border:0!important}[data-nav-tag=New]{color:#854d0e!important;background-color:#fef9c3!important;border:0!important}[data-nav-tag=生産終了]{color:#b91c1c!important;background-color:#fef2f2!important;border:0!important}[data-nav-tag=新製品],[data-nav-tag=단종]{color:#854d0e!important;background-color:#fef9c3!important;border:0!important}[data-nav-tag=단종]{color:#b91c1c!important;background-color:#fef2f2!important}[data-nav-tag=신제품]{color:#854d0e!important;background-color:#fef9c3!important;border:0!important}[data-nav-tag=\"Ngừng sản xuất\"]{color:#b91c1c!important;background-color:#fef2f2!important;border:0!important}[data-nav-tag=Mới]{color:#854d0e!important;background-color:#fef9c3!important;border:0!important}[data-nav-tag=Abgekündigt]{color:#b91c1c!important;background-color:#fef2f2!important;border:0!important}[data-nav-tag=Neu]{color:#854d0e!important;background-color:#fef9c3!important;border:0!important}[data-nav-tag=\"Fuori produzione\"]{color:#b91c1c!important;background-color:#fef2f2!important;border:0!important}[data-nav-tag=Novità]{color:#854d0e!important;background-color:#fef9c3!important;border:0!important}[data-nav-tag=Descatalogado]{color:#b91c1c!important;background-color:#fef2f2!important;border:0!important}[data-nav-tag=Nuevo]{color:#854d0e!important;background-color:#fef9c3!important;border:0!important}[data-nav-tag=\"Снят с производства\"]{color:#b91c1c!important;background-color:#fef2f2!important;border:0!important}[data-nav-tag=Новинка]{color:#854d0e!important;background-color:#fef9c3!important;border:0!important}html #sidebar-content a[href] .nav-tag-pill-text[data-nav-tag]{border:0 transparent!important;box-shadow:none!important}[data-nav-tag=即将发布]{color:#1d4ed8!important;background-color:#eff6ff!important;border:0!important;white-space:nowrap}.dark [data-nav-tag=即将发布]{color:#93c5fd!important;background-color:#172554!important}.mrdvs-video{width:100%;margin:1.5rem 0}.mrdvs-video-screen{position:relative;width:100%;aspect-ratio:16/9;overflow:hidden;border-radius:.875rem;background:#14141c}.mrdvs-video-screen iframe,.mrdvs-video-start{position:absolute;inset:0;display:block;width:100%;height:100%;border:0}.mrdvs-video-start{padding:0;cursor:pointer;color:#fff;background:#14141c}.mrdvs-video-start img{width:100%;height:100%;margin:0;object-fit:contain;opacity:.85}.mrdvs-video-start:hover img{opacity:1}.mrdvs-video-start:focus-visible{outline:3px solid #60a5fa;outline-offset:-4px}.mrdvs-video-label,.mrdvs-video-play{position:absolute;left:50%;background:rgb(20 20 28/88%)}.mrdvs-video-play{top:50%;display:grid;place-items:center;transform:translate(-50%,-50%);width:64px;height:64px;border-radius:50%;font-size:25px;padding-left:4px}.mrdvs-video-label{bottom:16px;transform:translateX(-50%);padding:4px 12px;border-radius:6px;font-size:14px;white-space:nowrap}.mrdvs-video figcaption{display:flex;justify-content:space-between;gap:.5rem 1rem;flex-wrap:wrap;margin-top:.6rem;font-size:14px;line-height:1.6}.mrdvs-video figcaption a{flex-shrink:0}.mrdvs-legacy-manual td p,.mrdvs-legacy-manual th p{margin:.25rem 0}[data-nav-tag=\"Coming soon\"],[data-nav-tag=\"In arrivo\"],[data-nav-tag=\"Sắp ra mắt\"],[data-nav-tag=\"출시 예정\"],[data-nav-tag=Demnächst],[data-nav-tag=Próximamente],[data-nav-tag=Скоро],[data-nav-tag=近日発売]{color:#1d4ed8!important;background-color:#eff6ff!important;border:0!important;white-space:nowrap}.dark [data-nav-tag=\"Coming soon\"],.dark [data-nav-tag=\"In arrivo\"],.dark [data-nav-tag=\"Sắp ra mắt\"],.dark [data-nav-tag=\"출시 예정\"],.dark [data-nav-tag=Demnächst],.dark [data-nav-tag=Próximamente],.dark [data-nav-tag=Скоро],.dark [data-nav-tag=近日発売]{color:#93c5fd!important;background-color:#172554!important}.mrdvs-youtube{min-height:200px;border:0}.mrdvs-product-family [data-component-part=card-image]{width:100%;height:auto;aspect-ratio:2/1;max-height:180px;object-fit:cover;object-position:center 70%}.mrdvs-product-family [data-component-part=card-content-container]{padding:14px 16px 16px}.mrdvs-product-family [data-component-part=card-content]{font-size:15px;line-height:1.6}.frame[data-name=frame]:has(img):not(:has(video,iframe)){padding:0;background:0 0;margin-top:1.5rem;margin-bottom:1.5rem}.frame[data-name=frame]:has(img):not(:has(video,iframe))>.absolute{display:none}.frame[data-name=frame]:has(img):not(:has(video,iframe)) img{max-width:100%;height:auto}.frame:has(.mrdvs-product-hero){max-width:560px;margin-left:auto;margin-right:auto}.frame .mrdvs-product-hero img{width:auto;max-height:360px;object-fit:contain}.frame:has(.mrdvs-imaging-demo){max-width:520px;margin-left:auto;margin-right:auto}#navbar .navbar-link a{background:0 0;color:#526079;box-shadow:none;border:0;padding:6px 0;border-radius:0}#navbar .navbar-link a:hover{color:#1248b8}#navbar .navbar-link a svg[style*=mask-image]{background-color:currentColor}#navbar .navbar-link a:focus-visible{outline:2px solid #1248b8;outline-offset:3px}#navbar #search-bar-entry{height:40px;border-radius:10px;background:#f8fafc}#navbar #topbar-cta-button a{min-height:36px;padding:7px 14px;color:#334155}#navbar #topbar-cta-button a>span{background:0 0;border:1px solid #d7dee8;border-radius:8px;box-shadow:none}#navbar #topbar-cta-button a .text-white{color:inherit}#navbar #topbar-cta-button a svg{display:none}#navbar #topbar-cta-button a:hover>span{background:#f4f7fb;border-color:#aebbd0}.dark #navbar #topbar-cta-button a,.dark #navbar .navbar-link a{color:#cbd5e1}.dark #navbar #search-bar-entry{background:#18202c}.dark #navbar #topbar-cta-button a>span{border-color:#475569}.dark #navbar #topbar-cta-button a:hover>span{background:#1e293b}@media (min-width:1024px){#navbar div:has(>a>.nav-logo){flex:0 0 auto}#navbar div:has(>#search-bar-entry){flex:1 1 360px;max-width:560px;min-width:120px;margin-left:auto}#navbar div:has(>nav[aria-label=Main]){flex:0 0 auto;margin-left:auto}#navbar nav[aria-label=Main]>ul{gap:20px}#navbar nav[aria-label=Main]>ul>:not([hidden])~:not([hidden]){margin-inline-start:0}#navbar div:has(>.nav-tabs){background:#f4f8ff;border-top:1px solid #eaf2ff;border-bottom:1px solid #e5efff}.dark #navbar div:has(>.nav-tabs){background:#141c2a;border-color:#263347}#content-container>div:has(>#content-area){padding-top:24px}#sidebar-content .pt-10{padding-top:24px}#sidebar-content div:has(>#navigation-items)>.sticky:first-child{height:24px}#content-side-layout{top:calc(var(--mintlify-slot-header-height, calc(4rem + var(--topbar-tabs-height, 0rem))) + var(--banner-height, 0px) + 24px)}}"}],"page":{"pagePath":"en/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance","slug":"/en/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance","pageMetadata":{"title":"Case study: 3D visual obstacle avoidance for a wheeled humanoid robot","sidebarTitle":"Wheeled humanoid obstacle avoidance","description":"An MRDVS S3 RGB-D ToF camera case study for near-floor obstacle perception on a VersaBot wheeled humanoid robot.","href":"/en/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance"},"description":{"compiledSource":"\"use strict\";\nconst {jsx: _jsx} = arguments[0];\nconst {useMDXComponents: _provideComponents} = arguments[0];\nfunction _createMdxContent(props) {\n const _components = {\n p: \"p\",\n ..._provideComponents(),\n ...props.components\n };\n return _jsx(_components.p, {\n children: \"An MRDVS S3 RGB-D ToF camera case study for near-floor obstacle perception on a VersaBot wheeled humanoid robot.\"\n });\n}\nfunction MDXContent(props = {}) {\n const {wrapper: MDXLayout} = {\n ..._provideComponents(),\n ...props.components\n };\n return MDXLayout ? _jsx(MDXLayout, {\n ...props,\n children: _jsx(_createMdxContent, {\n ...props\n })\n }) : _createMdxContent(props);\n}\nreturn {\n default: MDXContent\n};\n","frontmatter":{},"scope":{}},"pageType":"default","mdx":{"mdxSource":{"compiledSource":"\"use strict\";const{Fragment:_Fragment,jsx:_jsx,jsxs:_jsxs}=arguments[0];const{useMDXComponents:_provideComponents}=arguments[0];function _createMdxContent(props){const _components={li:`li`,p:`p`,strong:`strong`,ul:`ul`,..._provideComponents(),...props.components},{Frame,Heading,OptimizedImage,Warning}=_components;if(!Frame)_missingMdxReference(`Frame`,true);if(!Heading)_missingMdxReference(`Heading`,true);if(!OptimizedImage)_missingMdxReference(`OptimizedImage`,true);if(!Warning)_missingMdxReference(`Warning`,true);return _jsxs(_Fragment,{children:[_jsx(_components.p,{children:`When a wheeled humanoid robot moves through a factory or warehouse, it must cover near-floor and surrounding obstacles. VersaBot mounts an MRDVS S3 RGB-D ToF camera at the bottom of the robot to capture environmental data near its travel path.`}),`\n`,_jsx(Frame,{children:_jsx(OptimizedImage,{src:`https://mintcdn.com/mrdvs/TdShDuTINUEOVCXn/images/solutions/mobile-robots-cases-wheeled-humanoid-obstacle-avoidance-case-sharing-wheeled-humanoid-robot-3d-obstacle-avoidance.avif?fit=max\u0026auto=format\u0026n=TdShDuTINUEOVCXn\u0026q=85\u0026s=91742ec9eec5ae4977b89593c8915c65`,alt:`S3 camera mounted at the bottom of the VersaBot wheeled humanoid robot`,\"data-og-width\":`1200`,width:`1200`,\"data-og-height\":`2179`,height:`2179`,\"data-path\":`images/solutions/mobile-robots-cases-wheeled-humanoid-obstacle-avoidance-case-sharing-wheeled-humanoid-robot-3d-obstacle-avoidance.avif`,\"data-optimize\":`true`,\"data-opv\":`3`,srcset:`https://mintcdn.com/mrdvs/TdShDuTINUEOVCXn/images/solutions/mobile-robots-cases-wheeled-humanoid-obstacle-avoidance-case-sharing-wheeled-humanoid-robot-3d-obstacle-avoidance.avif?w=280\u0026fit=max\u0026auto=format\u0026n=TdShDuTINUEOVCXn\u0026q=85\u0026s=b0d6c62cff9c570a4233b351254731db 280w, https://mintcdn.com/mrdvs/TdShDuTINUEOVCXn/images/solutions/mobile-robots-cases-wheeled-humanoid-obstacle-avoidance-case-sharing-wheeled-humanoid-robot-3d-obstacle-avoidance.avif?w=560\u0026fit=max\u0026auto=format\u0026n=TdShDuTINUEOVCXn\u0026q=85\u0026s=e069421ff35a0ab45d8440b3962d4faa 560w, https://mintcdn.com/mrdvs/TdShDuTINUEOVCXn/images/solutions/mobile-robots-cases-wheeled-humanoid-obstacle-avoidance-case-sharing-wheeled-humanoid-robot-3d-obstacle-avoidance.avif?w=840\u0026fit=max\u0026auto=format\u0026n=TdShDuTINUEOVCXn\u0026q=85\u0026s=913d3298e190f22bd077cbf1c1deec8d 840w, https://mintcdn.com/mrdvs/TdShDuTINUEOVCXn/images/solutions/mobile-robots-cases-wheeled-humanoid-obstacle-avoidance-case-sharing-wheeled-humanoid-robot-3d-obstacle-avoidance.avif?w=1100\u0026fit=max\u0026auto=format\u0026n=TdShDuTINUEOVCXn\u0026q=85\u0026s=900231fa017288fcfbcbd180cacfcc85 1100w, https://mintcdn.com/mrdvs/TdShDuTINUEOVCXn/images/solutions/mobile-robots-cases-wheeled-humanoid-obstacle-avoidance-case-sharing-wheeled-humanoid-robot-3d-obstacle-avoidance.avif?w=1650\u0026fit=max\u0026auto=format\u0026n=TdShDuTINUEOVCXn\u0026q=85\u0026s=38e60f4f09e1a2cb0d64ccb1d7990cab 1650w, https://mintcdn.com/mrdvs/TdShDuTINUEOVCXn/images/solutions/mobile-robots-cases-wheeled-humanoid-obstacle-avoidance-case-sharing-wheeled-humanoid-robot-3d-obstacle-avoidance.avif?w=2500\u0026fit=max\u0026auto=format\u0026n=TdShDuTINUEOVCXn\u0026q=85\u0026s=6d222c2030a1e23e3984c9571e62e13b 2500w`})}),`\n`,_jsx(Heading,{level:`2`,id:`perception-design`,children:`Perception design`}),`\n`,_jsx(_components.p,{children:`The S3 captures RGB images and depth data together, providing distance, color, and texture information. Mounting the camera low on the robot brings near-floor obstacles into the field of view and supplies 3D perception inputs to the higher-level avoidance policy.`}),`\n`,_jsx(Heading,{level:`2`,id:`application-considerations`,children:`Application considerations`}),`\n`,_jsxs(_components.ul,{children:[`\n`,_jsxs(_components.li,{children:[_jsx(_components.strong,{children:`Near-floor coverage:`}),` Detect small obstacles and objects at the edge of the travel path.`]}),`\n`,_jsxs(_components.li,{children:[_jsx(_components.strong,{children:`Dynamic environments:`}),` Use perception data to identify people, carts, and other moving objects during operation.`]}),`\n`,_jsxs(_components.li,{children:[_jsx(_components.strong,{children:`Site adaptation:`}),` Field of view, vehicle speed, obstacle material, lighting, and chassis vibration affect actual performance.`]}),`\n`]}),`\n`,_jsx(Frame,{children:_jsx(`a`,{href:`https://www.youtube.com/@MRDVS-2024`,target:`_blank`,rel:`noopener noreferrer`,children:`MRDVS · YouTube`})}),`\n`,_jsx(Warning,{children:_jsx(_components.p,{children:`The 3D camera is one part of the perception chain. Configure and validate vehicle-level avoidance and safety policies using operating speed, braking capability, blind spots, and an on-site risk assessment.`})})]})}function MDXContent(props={}){const{wrapper:MDXLayout}={..._provideComponents(),...props.components};return MDXLayout?_jsx(MDXLayout,{...props,children:_jsx(_createMdxContent,{...props})}):_createMdxContent(props)}return{default:MDXContent};function _missingMdxReference(id,component){throw new Error(`Expected `+(component?`component`:`object`)+\" `\"+id+\"` to be defined: you likely forgot to import, pass, or provide it.\")}","frontmatter":{},"scope":{"config":{},"pageMetadata":{"title":"Case study: 3D visual obstacle avoidance for a wheeled humanoid robot","sidebarTitle":"Wheeled humanoid obstacle avoidance","description":"An MRDVS S3 RGB-D ToF camera case study for near-floor obstacle perception on a VersaBot wheeled humanoid robot.","href":"/en/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance"}}},"mdxSourceWithNoJs":null},"mdxExtracts":{"tableOfContents":[{"title":"Perception design","slug":"perception-design","depth":2,"children":[]},{"title":"Application considerations","slug":"application-considerations","depth":2,"children":[]}],"codeExamples":{}},"jsLinks":["/_mintlify/custom/mrdvs/378d39fdec417f5f/external-links.js","/_mintlify/custom/mrdvs/c54e1a04644ca15d/preview-navigation.js","/_mintlify/custom/mrdvs/dd034041c302a149/site-details.js","/_mintlify/custom/mrdvs/a09862a38ab1157d/public-email.js"],"subdomain":"mrdvs","siteName":"MRDVS","title":"Case study: 3D visual obstacle avoidance for a wheeled humanoid robot - MRDVS","navMaps":{"firstHrefInVersion":{},"firstHrefInLanguage":{"zh-CN":{"href":"/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance","matchLevel":1},"en":{"href":"/en/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance","matchLevel":0},"ja":{"href":"/ja/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance","matchLevel":1},"ko":{"href":"/ko/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance","matchLevel":1},"vi":{"href":"/vi/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance","matchLevel":1},"de":{"href":"/de/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance","matchLevel":1},"it":{"href":"/it/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance","matchLevel":1},"es":{"href":"/es/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance","matchLevel":1},"ru":{"href":"/ru/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance","matchLevel":1}}},"lastModified":"2026-10-15T03:47:40.354Z","originalFileLocation":"en/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance.mdx","locale":"en"},"headHtml":"\u003cscript data-mint-head>(function(){var d=document.documentElement,p=\"light\";if(!p){try{p=localStorage.getItem(\"isDarkMode\")}catch(e){}if(p==='true')p='dark';else if(p==='false')p='light';if(p!=='light'\u0026\u0026p!=='dark'\u0026\u0026p!=='system')p=\"light\"}var r=p==='system'?(matchMedia(\"(prefers-color-scheme: dark)\").matches?'dark':'light'):p;d.classList.remove(r==='dark'?'light':'dark');d.classList.add(r);d.setAttribute(\"data-theme-preference\",p)})();\u003c/script>\u003cmeta data-mint-head name=\"description\" content=\"An MRDVS S3 RGB-D ToF camera case study for near-floor obstacle perception on a VersaBot wheeled humanoid robot.\">\u003cmeta data-mint-head name=\"application-name\" content=\"MRDVS\">\u003cmeta data-mint-head name=\"generator\" content=\"Mintlify\">\u003clink data-mint-head rel=\"icon\" type=\"image/png\" sizes=\"192x192\" href=\"/mintlify-assets/_mintlify/favicons/mrdvs/QwnmvGNekAGjBlQD/_generated/favicon/android-chrome-192x192.png\" media=\"(prefers-color-scheme: light)\">\u003clink data-mint-head rel=\"apple-touch-icon\" type=\"image/png\" sizes=\"180x180\" href=\"/mintlify-assets/_mintlify/favicons/mrdvs/QwnmvGNekAGjBlQD/_generated/favicon/apple-touch-icon.png\">\u003clink data-mint-head rel=\"icon\" type=\"image/png\" sizes=\"16x16\" href=\"/mintlify-assets/_mintlify/favicons/mrdvs/QwnmvGNekAGjBlQD/_generated/favicon/favicon-16x16.png\" media=\"(prefers-color-scheme: light)\">\u003clink data-mint-head rel=\"icon\" type=\"image/png\" sizes=\"32x32\" href=\"/mintlify-assets/_mintlify/favicons/mrdvs/QwnmvGNekAGjBlQD/_generated/favicon/favicon-32x32.png\" media=\"(prefers-color-scheme: light)\">\u003clink data-mint-head rel=\"shortcut icon\" type=\"image/x-icon\" href=\"/mintlify-assets/_mintlify/favicons/mrdvs/QwnmvGNekAGjBlQD/_generated/favicon/favicon.ico\" media=\"(prefers-color-scheme: light)\">\u003clink data-mint-head rel=\"icon\" type=\"image/png\" sizes=\"192x192\" href=\"/mintlify-assets/_mintlify/favicons/mrdvs/QwnmvGNekAGjBlQD/_generated/favicon-dark/android-chrome-192x192.png\" media=\"(prefers-color-scheme: dark)\">\u003clink data-mint-head rel=\"icon\" type=\"image/png\" sizes=\"16x16\" href=\"/mintlify-assets/_mintlify/favicons/mrdvs/QwnmvGNekAGjBlQD/_generated/favicon-dark/favicon-16x16.png\" media=\"(prefers-color-scheme: dark)\">\u003clink data-mint-head rel=\"icon\" type=\"image/png\" sizes=\"32x32\" href=\"/mintlify-assets/_mintlify/favicons/mrdvs/QwnmvGNekAGjBlQD/_generated/favicon-dark/favicon-32x32.png\" media=\"(prefers-color-scheme: dark)\">\u003clink data-mint-head rel=\"shortcut icon\" type=\"image/x-icon\" href=\"/mintlify-assets/_mintlify/favicons/mrdvs/QwnmvGNekAGjBlQD/_generated/favicon-dark/favicon.ico\" media=\"(prefers-color-scheme: dark)\">\u003cmeta data-mint-head property=\"og:title\" content=\"Case study: 3D visual obstacle avoidance for a wheeled humanoid robot - MRDVS\">\u003cmeta data-mint-head property=\"og:description\" content=\"An MRDVS S3 RGB-D ToF camera case study for near-floor obstacle perception on a VersaBot wheeled humanoid robot.\">\u003cmeta data-mint-head property=\"og:site_name\" content=\"MRDVS\">\u003cmeta data-mint-head property=\"og:url\" content=\"https://docs.mrdvs.com/en/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance\">\u003cmeta data-mint-head property=\"og:type\" content=\"website\">\u003cmeta data-mint-head property=\"og:image\" content=\"https://mrdvs.mintlify.app/_mintlify/api/og/v2?division=Robot+perception+and+navigation\u0026amp;title=Case+study%3A+3D+visual+obstacle+avoidance+for+a+wheeled+humanoid+robot\u0026amp;description=An+MRDVS+S3+RGB-D+ToF+camera+case+study+for+near-floor+obstacle+perception+on+a+VersaBot+wheeled+humanoid+robot.\u0026amp;theme=202747420bf96d2e3b4223e2\u0026amp;signature=aab98b0a4daa82be9064247ac7a80461e0938e25201c4a8d04fc2717163524a8\">\u003cmeta data-mint-head property=\"og:image:width\" content=\"1200\">\u003cmeta data-mint-head property=\"og:image:height\" content=\"630\">\u003cmeta data-mint-head name=\"twitter:card\" content=\"summary_large_image\">\u003cmeta data-mint-head name=\"twitter:title\" content=\"Case study: 3D visual obstacle avoidance for a wheeled humanoid robot - MRDVS\">\u003cmeta data-mint-head name=\"twitter:description\" content=\"An MRDVS S3 RGB-D ToF camera case study for near-floor obstacle perception on a VersaBot wheeled humanoid robot.\">\u003cmeta data-mint-head name=\"twitter:image\" content=\"https://mrdvs.mintlify.app/_mintlify/api/og/v2?division=Robot+perception+and+navigation\u0026amp;title=Case+study%3A+3D+visual+obstacle+avoidance+for+a+wheeled+humanoid+robot\u0026amp;description=An+MRDVS+S3+RGB-D+ToF+camera+case+study+for+near-floor+obstacle+perception+on+a+VersaBot+wheeled+humanoid+robot.\u0026amp;theme=202747420bf96d2e3b4223e2\u0026amp;signature=aab98b0a4daa82be9064247ac7a80461e0938e25201c4a8d04fc2717163524a8\">\u003cmeta data-mint-head name=\"twitter:image:width\" content=\"1200\">\u003cmeta data-mint-head name=\"twitter:image:height\" content=\"630\">\u003cmeta data-mint-head name=\"msapplication-config\" content=\"/mintlify-assets/_mintlify/favicons/mrdvs/QwnmvGNekAGjBlQD/_generated/favicon/browserconfig.xml\">\u003cmeta data-mint-head name=\"apple-mobile-web-app-title\" content=\"MRDVS\">\u003cmeta data-mint-head name=\"msapplication-TileColor\" content=\"#1248B8\">\u003cmeta data-mint-head name=\"google-site-verification\" content=\"paNq6FdXn6w3vlYqGqsx4YFtZgIyoE54Ya803O0ilNM\">\u003cmeta data-mint-head name=\"baidu-site-verification\" content=\"codeva-aVWshvu4wM\">\u003cmeta data-mint-head name=\"msvalidate.01\" content=\"79667988DD5B77655E355B82AFD283E3\">\u003clink data-mint-head rel=\"canonical\" href=\"https://docs.mrdvs.com/en/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance\">\u003clink data-mint-head rel=\"alternate\" type=\"application/xml\" href=\"/sitemap.xml\">\u003clink data-mint-head rel=\"alternate\" type=\"text/markdown\" href=\"/en/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance.md\">\u003clink data-mint-head rel=\"alternate\" hreflang=\"en\" href=\"https://docs.mrdvs.com/en/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance\">\u003clink data-mint-head rel=\"alternate\" hreflang=\"zh-CN\" href=\"https://docs.mrdvs.com/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance\">\u003clink data-mint-head rel=\"alternate\" hreflang=\"ja\" href=\"https://docs.mrdvs.com/ja/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance\">\u003clink data-mint-head rel=\"alternate\" hreflang=\"ko\" href=\"https://docs.mrdvs.com/ko/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance\">\u003clink data-mint-head rel=\"alternate\" hreflang=\"vi\" href=\"https://docs.mrdvs.com/vi/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance\">\u003clink data-mint-head rel=\"alternate\" hreflang=\"de\" href=\"https://docs.mrdvs.com/de/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance\">\u003clink data-mint-head rel=\"alternate\" hreflang=\"it\" href=\"https://docs.mrdvs.com/it/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance\">\u003clink data-mint-head rel=\"alternate\" hreflang=\"es\" href=\"https://docs.mrdvs.com/es/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance\">\u003clink data-mint-head rel=\"alternate\" hreflang=\"ru\" href=\"https://docs.mrdvs.com/ru/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance\">\u003clink data-mint-head rel=\"alternate\" hreflang=\"x-default\" href=\"https://docs.mrdvs.com/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance\">\u003cscript data-mint-head type=\"application/ld+json\">{\"@context\":\"https://schema.org\",\"@graph\":[{\"@type\":\"Organization\",\"@id\":\"https://docs.mrdvs.com/#organization\",\"name\":\"MRDVS\",\"url\":\"https://docs.mrdvs.com\",\"logo\":{\"@type\":\"ImageObject\",\"url\":\"https://mintcdn.com/mrdvs/gEte5Lm3vPtLdk_a/logo/logo.svg?fit=max\u0026auto=format\u0026n=gEte5Lm3vPtLdk_a\u0026q=85\u0026s=1d0001033c0b1f686e1d5e4c6576c469\"}},{\"@type\":\"WebSite\",\"@id\":\"https://docs.mrdvs.com#website\",\"name\":\"MRDVS\",\"url\":\"https://docs.mrdvs.com\",\"publisher\":{\"@id\":\"https://docs.mrdvs.com/#organization\"}},{\"@type\":\"WebPage\",\"@id\":\"https://docs.mrdvs.com/en/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance#webpage\",\"url\":\"https://docs.mrdvs.com/en/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance\",\"name\":\"Case study: 3D visual obstacle avoidance for a wheeled humanoid robot\",\"description\":\"An MRDVS S3 RGB-D ToF camera case study for near-floor obstacle perception on a VersaBot wheeled humanoid robot.\",\"dateModified\":\"2026-10-15T03:47:40.354Z\",\"isPartOf\":{\"@id\":\"https://docs.mrdvs.com#website\"},\"breadcrumb\":{\"@id\":\"https://docs.mrdvs.com/en/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance#breadcrumb\"}},{\"@type\":\"BreadcrumbList\",\"@id\":\"https://docs.mrdvs.com/en/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance#breadcrumb\",\"itemListElement\":[{\"@type\":\"ListItem\",\"position\":1,\"name\":\"Solutions and case studies\",\"item\":\"https://docs.mrdvs.com/en/solutions/warehouse/bin-stacking\"},{\"@type\":\"ListItem\",\"position\":2,\"name\":\"Robot perception and navigation\",\"item\":\"https://docs.mrdvs.com/en/solutions/mobile-robots/cases/slam-in-industrial-environments\"},{\"@type\":\"ListItem\",\"position\":3,\"name\":\"Case study: 3D visual obstacle avoidance for a wheeled humanoid robot\",\"item\":\"https://docs.mrdvs.com/en/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance\"}]},{\"@type\":[\"Article\",\"TechArticle\"],\"@id\":\"https://docs.mrdvs.com/en/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance#article\",\"headline\":\"Case study: 3D visual obstacle avoidance for a wheeled humanoid robot\",\"name\":\"Case study: 3D visual obstacle avoidance for a wheeled humanoid robot\",\"description\":\"An MRDVS S3 RGB-D ToF camera case study for near-floor obstacle perception on a VersaBot wheeled humanoid robot.\",\"url\":\"https://docs.mrdvs.com/en/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance\",\"mainEntityOfPage\":{\"@id\":\"https://docs.mrdvs.com/en/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance#webpage\"},\"dateModified\":\"2026-10-15T03:47:40.354Z\",\"publisher\":{\"@id\":\"https://docs.mrdvs.com/#organization\"},\"isPartOf\":{\"@id\":\"https://docs.mrdvs.com#website\"}}]}\u003c/script>\u003cscript data-mint-head type=\"application/ld+json\">{\"@context\":\"https://schema.org\",\"@type\":\"WebSite\",\"name\":\"MRDVS\",\"creator\":{\"@type\":\"Organization\",\"name\":\"Mintlify\",\"url\":\"https://mintlify.com\"}}\u003c/script>","siteName":"MRDVS","nav":{"global":null,"languages":[{"language":"zh-CN","default":true,"footer":{"socials":{"github":"https://github.com/Lanxin-MRDVS/CameraSDK","linkedin":"https://www.linkedin.com/company/mrdvs","youtube":"https://www.youtube.com/@MRDVS-2024","website":"https://www.mrdvs.cn/"},"links":[{"header":"产品","items":[{"label":"S 系列3D相机","href":"https://www.mrdvs.cn/product/3d-obstacle-avoidance-cameras-s-series"},{"label":"M 系列3D相机","href":"https://www.mrdvs.cn/product/m-series"},{"label":"V 系列导航模组","href":"https://www.mrdvs.cn/product/v-series"}]},{"header":"解决方案","items":[{"label":"移动机器人视觉","href":"https://www.mrdvs.cn/solutions/solutions-industrial-mobile-robot"},{"label":"仓储物流自动化","href":"https://www.mrdvs.cn/solutions/solutions-warehouse-visual-perception"},{"label":"无人机视觉感知","href":"https://www.mrdvs.cn/solutions/solutions-drones"}]},{"header":"联系我们","items":[{"label":"关于 MRDVS","href":"/about"},{"label":"售前咨询","href":"https://work.weixin.qq.com/ca/cawcde978188b336f1"},{"label":"电话:400-025-6680","href":"/contact"},{"label":"[email protected]","href":"mailto:[email protected]"},{"label":"浙ICP备2023021387号-2","href":"https://beian.miit.gov.cn/"}]}]},"navbar":{"links":[{"icon":{"style":"brands","name":"github"},"href":"https://github.com/Lanxin-MRDVS","label":"GitHub"},{"icon":"/images/favicon.png","href":"https://www.mrdvs.cn/","label":"MRDVS"}],"primary":{"type":"button","label":"联系我们","href":"https://work.weixin.qq.com/ca/cawcde978188b336f1"}},"pages":[{"title":"zh-CN","href":"/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance"}]},{"language":"en","footer":{"socials":{"github":"https://github.com/Lanxin-MRDVS/CameraSDK","linkedin":"https://www.linkedin.com/company/mrdvs","youtube":"https://www.youtube.com/@MRDVS-2024","website":"https://mrdvs.com/"},"links":[{"header":"Products","items":[{"label":"S Series 3D Cameras","href":"https://mrdvs.com/s-series-obstacle-avoidance-robot-cameras"},{"label":"M Series 3D Cameras","href":"https://mrdvs.com/m-series-time-of-flight-camera"},{"label":"V Series Localization","href":"https://mrdvs.com/v2-pro-rtls-slam-solution"}]},{"header":"Solutions","items":[{"label":"Mobile Robot Vision","href":"https://mrdvs.com/humanoids-quadrupeds-robots"},{"label":"Warehouse \u0026 Logistics","href":"https://mrdvs.com/vision-guided-robotics"},{"label":"Lawn Mower Perception","href":"https://mrdvs.com/solid-state-lidar-vision-fusion"}]},{"header":"Contact Us","items":[{"label":"About MRDVS","href":"/en/about"},{"label":"WhatsApp","href":"https://wa.me/8613370882355"},{"label":"[email protected]","href":"mailto:[email protected]"}]}]},"navbar":{"links":[{"icon":{"style":"brands","name":"github"},"href":"https://github.com/Lanxin-MRDVS","label":"GitHub"},{"icon":"/images/favicon.png","href":"https://mrdvs.com/","label":"MRDVS"}],"primary":{"type":"button","label":"Contact Us","href":"/en/contact"}},"tabs":[{"tab":"Home","pages":[{"title":"Home","href":"/en"}]},{"tab":"Vision hardware","pages":[{"title":"Vision hardware","href":"/en/products/overview"}]},{"tab":"Industrial solutions","groups":[{"group":"Overview","pages":[{"title":"Industrial solutions","href":"/en/solutions"}]},{"group":"Warehouse and logistics","pages":[{"title":"Application platform","href":"/en/solutions/aw3"},{"title":"Pallet docking","href":"/en/solutions/warehouse/pallet-recognition"},{"title":"Storage location monitoring","href":"/en/solutions/warehouse/bin-location-status"},{"title":"Depalletizing","href":"/en/solutions/warehouse/soft-package-depalletizing"},{"title":"Human safety monitoring","href":"/en/solutions/mobile-robots/human-safety"},{"title":"Volume measurement","href":"/en/solutions/warehouse/volume-measurement"}]},{"group":"Mobile robots","pages":[{"title":"3D obstacle avoidance","href":"/en/solutions/mobile-robots/3d-obstacle-avoidance"},{"title":"V2Pro Localization and Navigation Module","href":"/en/solutions/mobile-robots/slam-localization"}]},{"group":"Solutions and case studies","pages":[{"group":"Warehouse automation and handling","expanded":false,"pages":[{"title":"AGV forklift bin stacking","href":"/en/solutions/warehouse/bin-stacking"},{"title":"3D vision for automated-storage safety","sidebarTitle":"Automated storage safety","href":"/en/solutions/warehouse/automated-storage-safety"},{"title":"Case study: Automated soft-package depalletizing at a chemical producer","sidebarTitle":"Chemical soft-package depalletizing","href":"/en/solutions/warehouse/cases/chemical-soft-package-depalletizing"},{"title":"Case study: Non-standard pallet recognition for Jushi Group","sidebarTitle":"Non-standard pallet recognition","href":"/en/solutions/warehouse/cases/jushi-nonstandard-pallet-recognition"},{"title":"Case study: Storage-location status recognition in an automated warehouse","sidebarTitle":"Storage-location status recognition","href":"/en/solutions/warehouse/cases/bin-location-status"},{"title":"Case study: Bin stacking at an automotive logistics center","sidebarTitle":"Automotive bin stacking","href":"/en/solutions/warehouse/cases/automotive-bin-stacking"},{"title":"Case study: An unmanned forklift completes more than 500 tasks per day","sidebarTitle":"Unmanned forklift: 500+ tasks","href":"/en/solutions/warehouse/cases/unmanned-forklift-500-tasks"},{"title":"Case study: Top-view navigation for an unmanned forklift serving 3,000+ locations","sidebarTitle":"Top-view navigation for 3,000+ locations","href":"/en/solutions/warehouse/cases/overhead-navigation-3000-locations"}]},{"group":"Robot perception and navigation","expanded":false,"pages":[{"title":"Case study: Visual SLAM navigation in industrial environments","sidebarTitle":"Industrial SLAM navigation","href":"/en/solutions/mobile-robots/cases/slam-in-industrial-environments"},{"title":"Case study: 3D vision for a humanoid robot","sidebarTitle":"Humanoid robot 3D vision","href":"/en/solutions/mobile-robots/cases/humanoid-robot-3d-vision"},{"title":"Case study: 3D visual obstacle avoidance for an under-ride AMR","sidebarTitle":"Under-ride AMR obstacle avoidance","description":"An S Series RGB-D camera case study for obstacle avoidance and cart docking on an under-ride AMR at Dynabook's China production site.","href":"/en/solutions/mobile-robots/cases/under-ride-amr-obstacle-avoidance"},{"title":"Case study: 3D visual obstacle avoidance for a wheeled humanoid robot","sidebarTitle":"Wheeled humanoid obstacle avoidance","href":"/en/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance"}]},{"group":"Smart agriculture","expanded":false,"pages":[{"title":"Vision-guided fruit and vegetable harvesting","sidebarTitle":"Vision-guided harvesting","description":"A vision solution for agricultural robots that addresses foliage occlusion, changing daylight, and fruit localization.","href":"/en/solutions/agriculture/robotic-harvesting"}]}]}]},{"tab":"Developers","pages":[{"title":"Developers","href":"/en/developers"}]},{"tab":"Support and downloads","pages":[{"title":"Support and downloads","href":"/en/resources"}]}]},{"language":"ja","footer":{"socials":{"github":"https://github.com/Lanxin-MRDVS/CameraSDK","linkedin":"https://www.linkedin.com/company/mrdvs","youtube":"https://www.youtube.com/@MRDVS-2024","website":"https://mrdvs.com/"},"links":[{"header":"製品","items":[{"label":"Sシリーズ3Dカメラ","href":"https://mrdvs.com/s-series-obstacle-avoidance-robot-cameras"},{"label":"Mシリーズ3Dカメラ","href":"https://mrdvs.com/m-series-time-of-flight-camera"},{"label":"Vシリーズローカライゼーション","href":"https://mrdvs.com/v2-pro-rtls-slam-solution"}]},{"header":"ソリューション","items":[{"label":"モバイルロボットビジョン","href":"https://mrdvs.com/humanoids-quadrupeds-robots"},{"label":"倉庫・物流","href":"https://mrdvs.com/vision-guided-robotics"},{"label":"芝刈り機向け認識","href":"https://mrdvs.com/solid-state-lidar-vision-fusion"}]},{"header":"お問い合わせ","items":[{"label":"MRDVSについて","href":"/ja/about"},{"label":"WhatsApp","href":"https://wa.me/8613370882355"},{"label":"[email protected]","href":"mailto:[email protected]"}]}]},"navbar":{"links":[{"icon":{"style":"brands","name":"github"},"href":"https://github.com/Lanxin-MRDVS","label":"GitHub"},{"icon":"/images/favicon.png","href":"https://mrdvs.com/","label":"MRDVS"}],"primary":{"type":"button","label":"お問い合わせ","href":"/ja/contact"}},"pages":[{"title":"ja","href":"/ja/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance"}]},{"language":"ko","footer":{"socials":{"github":"https://github.com/Lanxin-MRDVS/CameraSDK","linkedin":"https://www.linkedin.com/company/mrdvs","youtube":"https://www.youtube.com/@MRDVS-2024","website":"https://mrdvs.com/"},"links":[{"header":"제품","items":[{"label":"S 시리즈 3D 카메라","href":"https://mrdvs.com/s-series-obstacle-avoidance-robot-cameras"},{"label":"M 시리즈 3D 카메라","href":"https://mrdvs.com/m-series-time-of-flight-camera"},{"label":"V 시리즈 위치 추정","href":"https://mrdvs.com/v2-pro-rtls-slam-solution"}]},{"header":"솔루션","items":[{"label":"이동 로봇 비전","href":"https://mrdvs.com/humanoids-quadrupeds-robots"},{"label":"창고 및 물류","href":"https://mrdvs.com/vision-guided-robotics"},{"label":"잔디깎이 로봇 인식","href":"https://mrdvs.com/solid-state-lidar-vision-fusion"}]},{"header":"문의","items":[{"label":"MRDVS 소개","href":"/ko/about"},{"label":"WhatsApp","href":"https://wa.me/8613370882355"},{"label":"[email protected]","href":"mailto:[email protected]"}]}]},"navbar":{"links":[{"icon":{"style":"brands","name":"github"},"href":"https://github.com/Lanxin-MRDVS","label":"GitHub"},{"icon":"/images/favicon.png","href":"https://mrdvs.com/","label":"MRDVS"}],"primary":{"type":"button","label":"문의하기","href":"/ko/contact"}},"pages":[{"title":"ko","href":"/ko/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance"}]},{"language":"vi","footer":{"socials":{"github":"https://github.com/Lanxin-MRDVS/CameraSDK","linkedin":"https://www.linkedin.com/company/mrdvs","youtube":"https://www.youtube.com/@MRDVS-2024","website":"https://mrdvs.com/"},"links":[{"header":"Sản phẩm","items":[{"label":"Camera 3D dòng S","href":"https://mrdvs.com/s-series-obstacle-avoidance-robot-cameras"},{"label":"Camera 3D dòng M","href":"https://mrdvs.com/m-series-time-of-flight-camera"},{"label":"Định vị dòng V","href":"https://mrdvs.com/v2-pro-rtls-slam-solution"}]},{"header":"Giải pháp","items":[{"label":"Thị giác robot di động","href":"https://mrdvs.com/humanoids-quadrupeds-robots"},{"label":"Kho vận \u0026 logistics","href":"https://mrdvs.com/vision-guided-robotics"},{"label":"Nhận thức cho máy cắt cỏ","href":"https://mrdvs.com/solid-state-lidar-vision-fusion"}]},{"header":"Liên hệ","items":[{"label":"Giới thiệu MRDVS","href":"/vi/about"},{"label":"WhatsApp","href":"https://wa.me/8613370882355"},{"label":"[email protected]","href":"mailto:[email protected]"}]}]},"navbar":{"links":[{"icon":{"style":"brands","name":"github"},"href":"https://github.com/Lanxin-MRDVS","label":"GitHub"},{"icon":"/images/favicon.png","href":"https://mrdvs.com/","label":"MRDVS"}],"primary":{"type":"button","label":"Liên hệ","href":"/vi/contact"}},"pages":[{"title":"vi","href":"/vi/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance"}]},{"language":"de","footer":{"socials":{"github":"https://github.com/Lanxin-MRDVS/CameraSDK","linkedin":"https://www.linkedin.com/company/mrdvs","youtube":"https://www.youtube.com/@MRDVS-2024","website":"https://mrdvs.com/"},"links":[{"header":"Produkte","items":[{"label":"3D-Kameras der S-Serie","href":"https://mrdvs.com/s-series-obstacle-avoidance-robot-cameras"},{"label":"3D-Kameras der M-Serie","href":"https://mrdvs.com/m-series-time-of-flight-camera"},{"label":"Lokalisierung der V-Serie","href":"https://mrdvs.com/v2-pro-rtls-slam-solution"}]},{"header":"Lösungen","items":[{"label":"Robotersicht für mobile Roboter","href":"https://mrdvs.com/humanoids-quadrupeds-robots"},{"label":"Lager und Logistik","href":"https://mrdvs.com/vision-guided-robotics"},{"label":"Wahrnehmung für Rasenmäher","href":"https://mrdvs.com/solid-state-lidar-vision-fusion"}]},{"header":"Kontakt","items":[{"label":"Über MRDVS","href":"/de/about"},{"label":"WhatsApp","href":"https://wa.me/8613370882355"},{"label":"[email protected]","href":"mailto:[email protected]"}]}]},"navbar":{"links":[{"icon":{"style":"brands","name":"github"},"href":"https://github.com/Lanxin-MRDVS","label":"GitHub"},{"icon":"/images/favicon.png","href":"https://mrdvs.com/","label":"MRDVS"}],"primary":{"type":"button","label":"Kontakt","href":"/de/contact"}},"pages":[{"title":"de","href":"/de/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance"}]},{"language":"it","footer":{"socials":{"github":"https://github.com/Lanxin-MRDVS/CameraSDK","linkedin":"https://www.linkedin.com/company/mrdvs","youtube":"https://www.youtube.com/@MRDVS-2024","website":"https://mrdvs.com/"},"links":[{"header":"Prodotti","items":[{"label":"Telecamere 3D serie S","href":"https://mrdvs.com/s-series-obstacle-avoidance-robot-cameras"},{"label":"Telecamere 3D serie M","href":"https://mrdvs.com/m-series-time-of-flight-camera"},{"label":"Localizzazione serie V","href":"https://mrdvs.com/v2-pro-rtls-slam-solution"}]},{"header":"Soluzioni","items":[{"label":"Visione per robot mobili","href":"https://mrdvs.com/humanoids-quadrupeds-robots"},{"label":"Magazzino e logistica","href":"https://mrdvs.com/vision-guided-robotics"},{"label":"Percezione per rasaerba","href":"https://mrdvs.com/solid-state-lidar-vision-fusion"}]},{"header":"Contatti","items":[{"label":"Informazioni su MRDVS","href":"/it/about"},{"label":"WhatsApp","href":"https://wa.me/8613370882355"},{"label":"[email protected]","href":"mailto:[email protected]"}]}]},"navbar":{"links":[{"icon":{"style":"brands","name":"github"},"href":"https://github.com/Lanxin-MRDVS","label":"GitHub"},{"icon":"/images/favicon.png","href":"https://mrdvs.com/","label":"MRDVS"}],"primary":{"type":"button","label":"Contatti","href":"/it/contact"}},"pages":[{"title":"it","href":"/it/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance"}]},{"language":"es","footer":{"socials":{"github":"https://github.com/Lanxin-MRDVS/CameraSDK","linkedin":"https://www.linkedin.com/company/mrdvs","youtube":"https://www.youtube.com/@MRDVS-2024","website":"https://mrdvs.com/"},"links":[{"header":"Productos","items":[{"label":"Cámaras 3D de la serie S","href":"https://mrdvs.com/s-series-obstacle-avoidance-robot-cameras"},{"label":"Cámaras 3D de la serie M","href":"https://mrdvs.com/m-series-time-of-flight-camera"},{"label":"Localización de la serie V","href":"https://mrdvs.com/v2-pro-rtls-slam-solution"}]},{"header":"Soluciones","items":[{"label":"Visión para robots móviles","href":"https://mrdvs.com/humanoids-quadrupeds-robots"},{"label":"Almacén y logística","href":"https://mrdvs.com/vision-guided-robotics"},{"label":"Percepción para cortacéspedes","href":"https://mrdvs.com/solid-state-lidar-vision-fusion"}]},{"header":"Contacto","items":[{"label":"Acerca de MRDVS","href":"/es/about"},{"label":"WhatsApp","href":"https://wa.me/8613370882355"},{"label":"[email protected]","href":"mailto:[email protected]"}]}]},"navbar":{"links":[{"icon":{"style":"brands","name":"github"},"href":"https://github.com/Lanxin-MRDVS","label":"GitHub"},{"icon":"/images/favicon.png","href":"https://mrdvs.com/","label":"MRDVS"}],"primary":{"type":"button","label":"Contacto","href":"/es/contact"}},"pages":[{"title":"es","href":"/es/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance"}]},{"language":"ru","footer":{"socials":{"github":"https://github.com/Lanxin-MRDVS/CameraSDK","linkedin":"https://www.linkedin.com/company/mrdvs","youtube":"https://www.youtube.com/@MRDVS-2024","website":"https://mrdvs.com/"},"links":[{"header":"Продукты","items":[{"label":"3D-камеры серии S","href":"https://mrdvs.com/s-series-obstacle-avoidance-robot-cameras"},{"label":"3D-камеры серии M","href":"https://mrdvs.com/m-series-time-of-flight-camera"},{"label":"Локализация серии V","href":"https://mrdvs.com/v2-pro-rtls-slam-solution"}]},{"header":"Решения","items":[{"label":"Зрение мобильных роботов","href":"https://mrdvs.com/humanoids-quadrupeds-robots"},{"label":"Склад и логистика","href":"https://mrdvs.com/vision-guided-robotics"},{"label":"Восприятие для газонокосилок","href":"https://mrdvs.com/solid-state-lidar-vision-fusion"}]},{"header":"Связаться с нами","items":[{"label":"О MRDVS","href":"/ru/about"},{"label":"WhatsApp","href":"https://wa.me/8613370882355"},{"label":"[email protected]","href":"mailto:[email protected]"}]}]},"navbar":{"links":[{"icon":{"style":"brands","name":"github"},"href":"https://github.com/Lanxin-MRDVS","label":"GitHub"},{"icon":"/images/favicon.png","href":"https://mrdvs.com/","label":"MRDVS"}],"primary":{"type":"button","label":"Связаться с нами","href":"/ru/contact"}},"pages":[{"title":"ru","href":"/ru/solutions/mobile-robots/cases/wheeled-humanoid-obstacle-avoidance"}]}]},"title":"Case study: 3D visual obstacle avoidance for a wheeled humanoid robot - MRDVS","buildId":"dpl_849ArpqvBiCczQiT1Y1stNGpbqHT","deploymentId":"dpl_849ArpqvBiCczQiT1Y1stNGpbqHT","dynamics":["07c022d89b","a74be98ba7"],"chunks":["Frame-Cz91mEGH.js","DynamicMarkdown-a8hUKrw6.js","zoom-image-lightbox-CaUwvYH3.js","lightbox-handle-r17bVUz3.js"]}