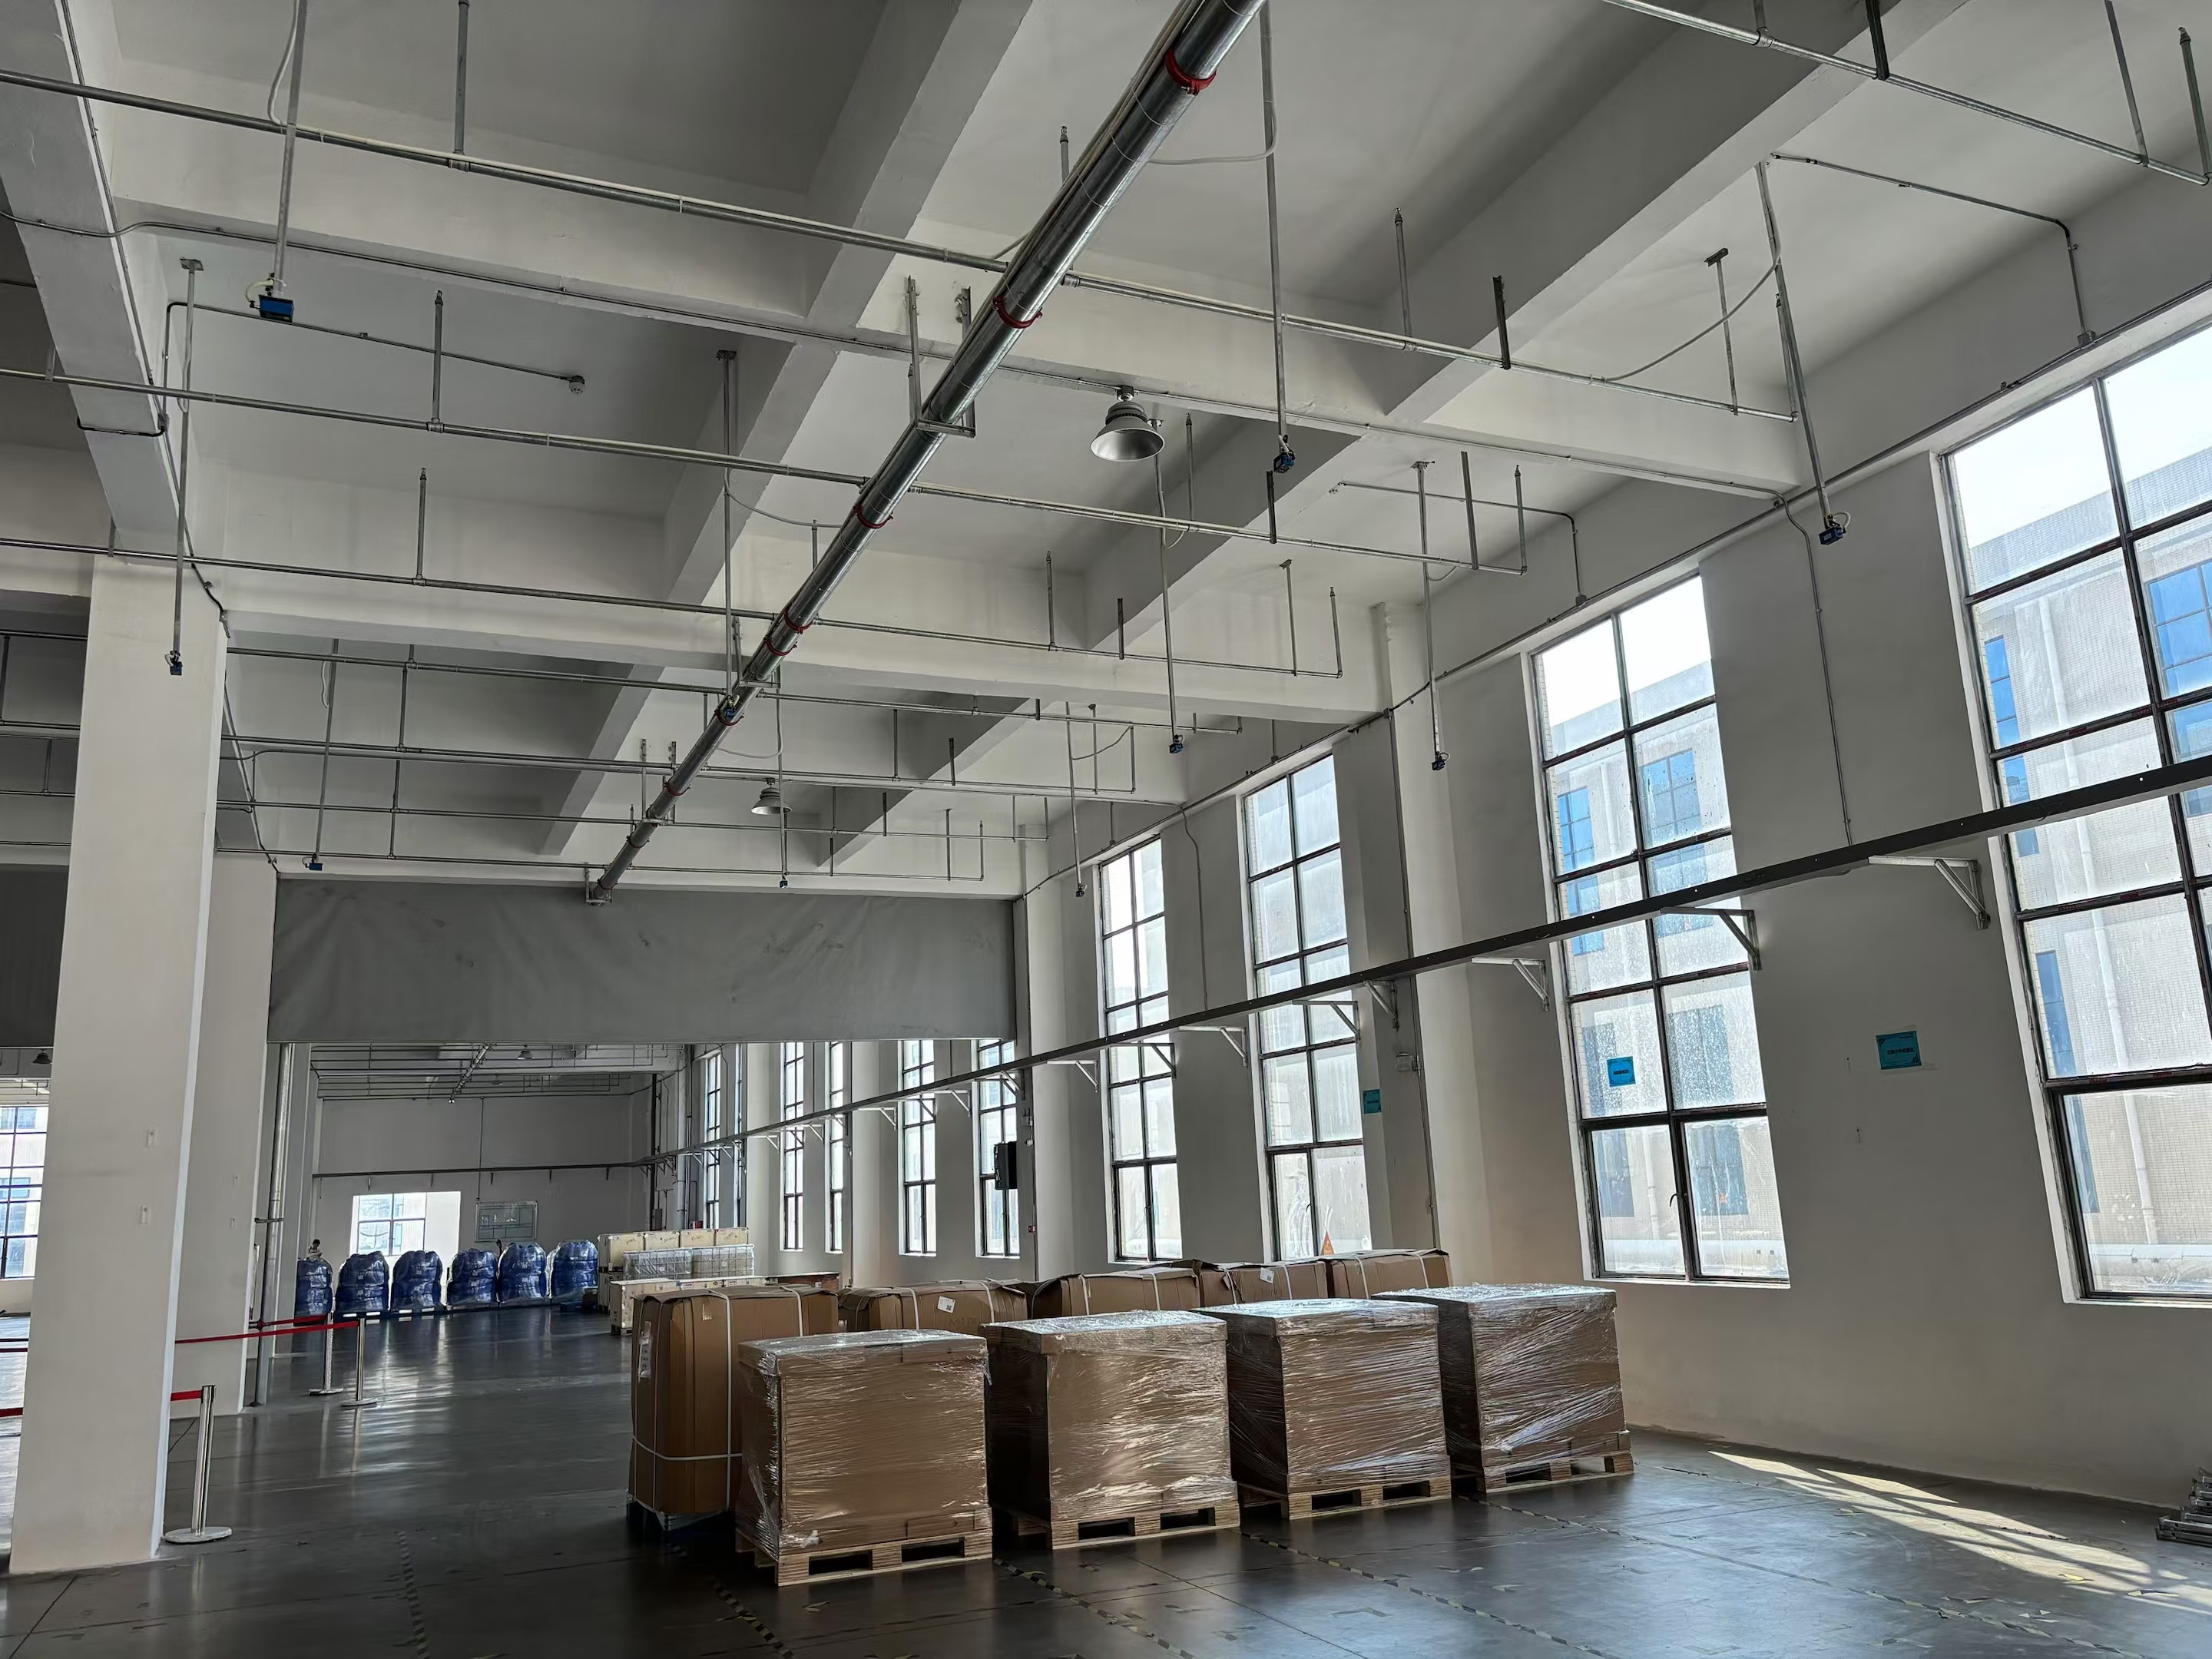
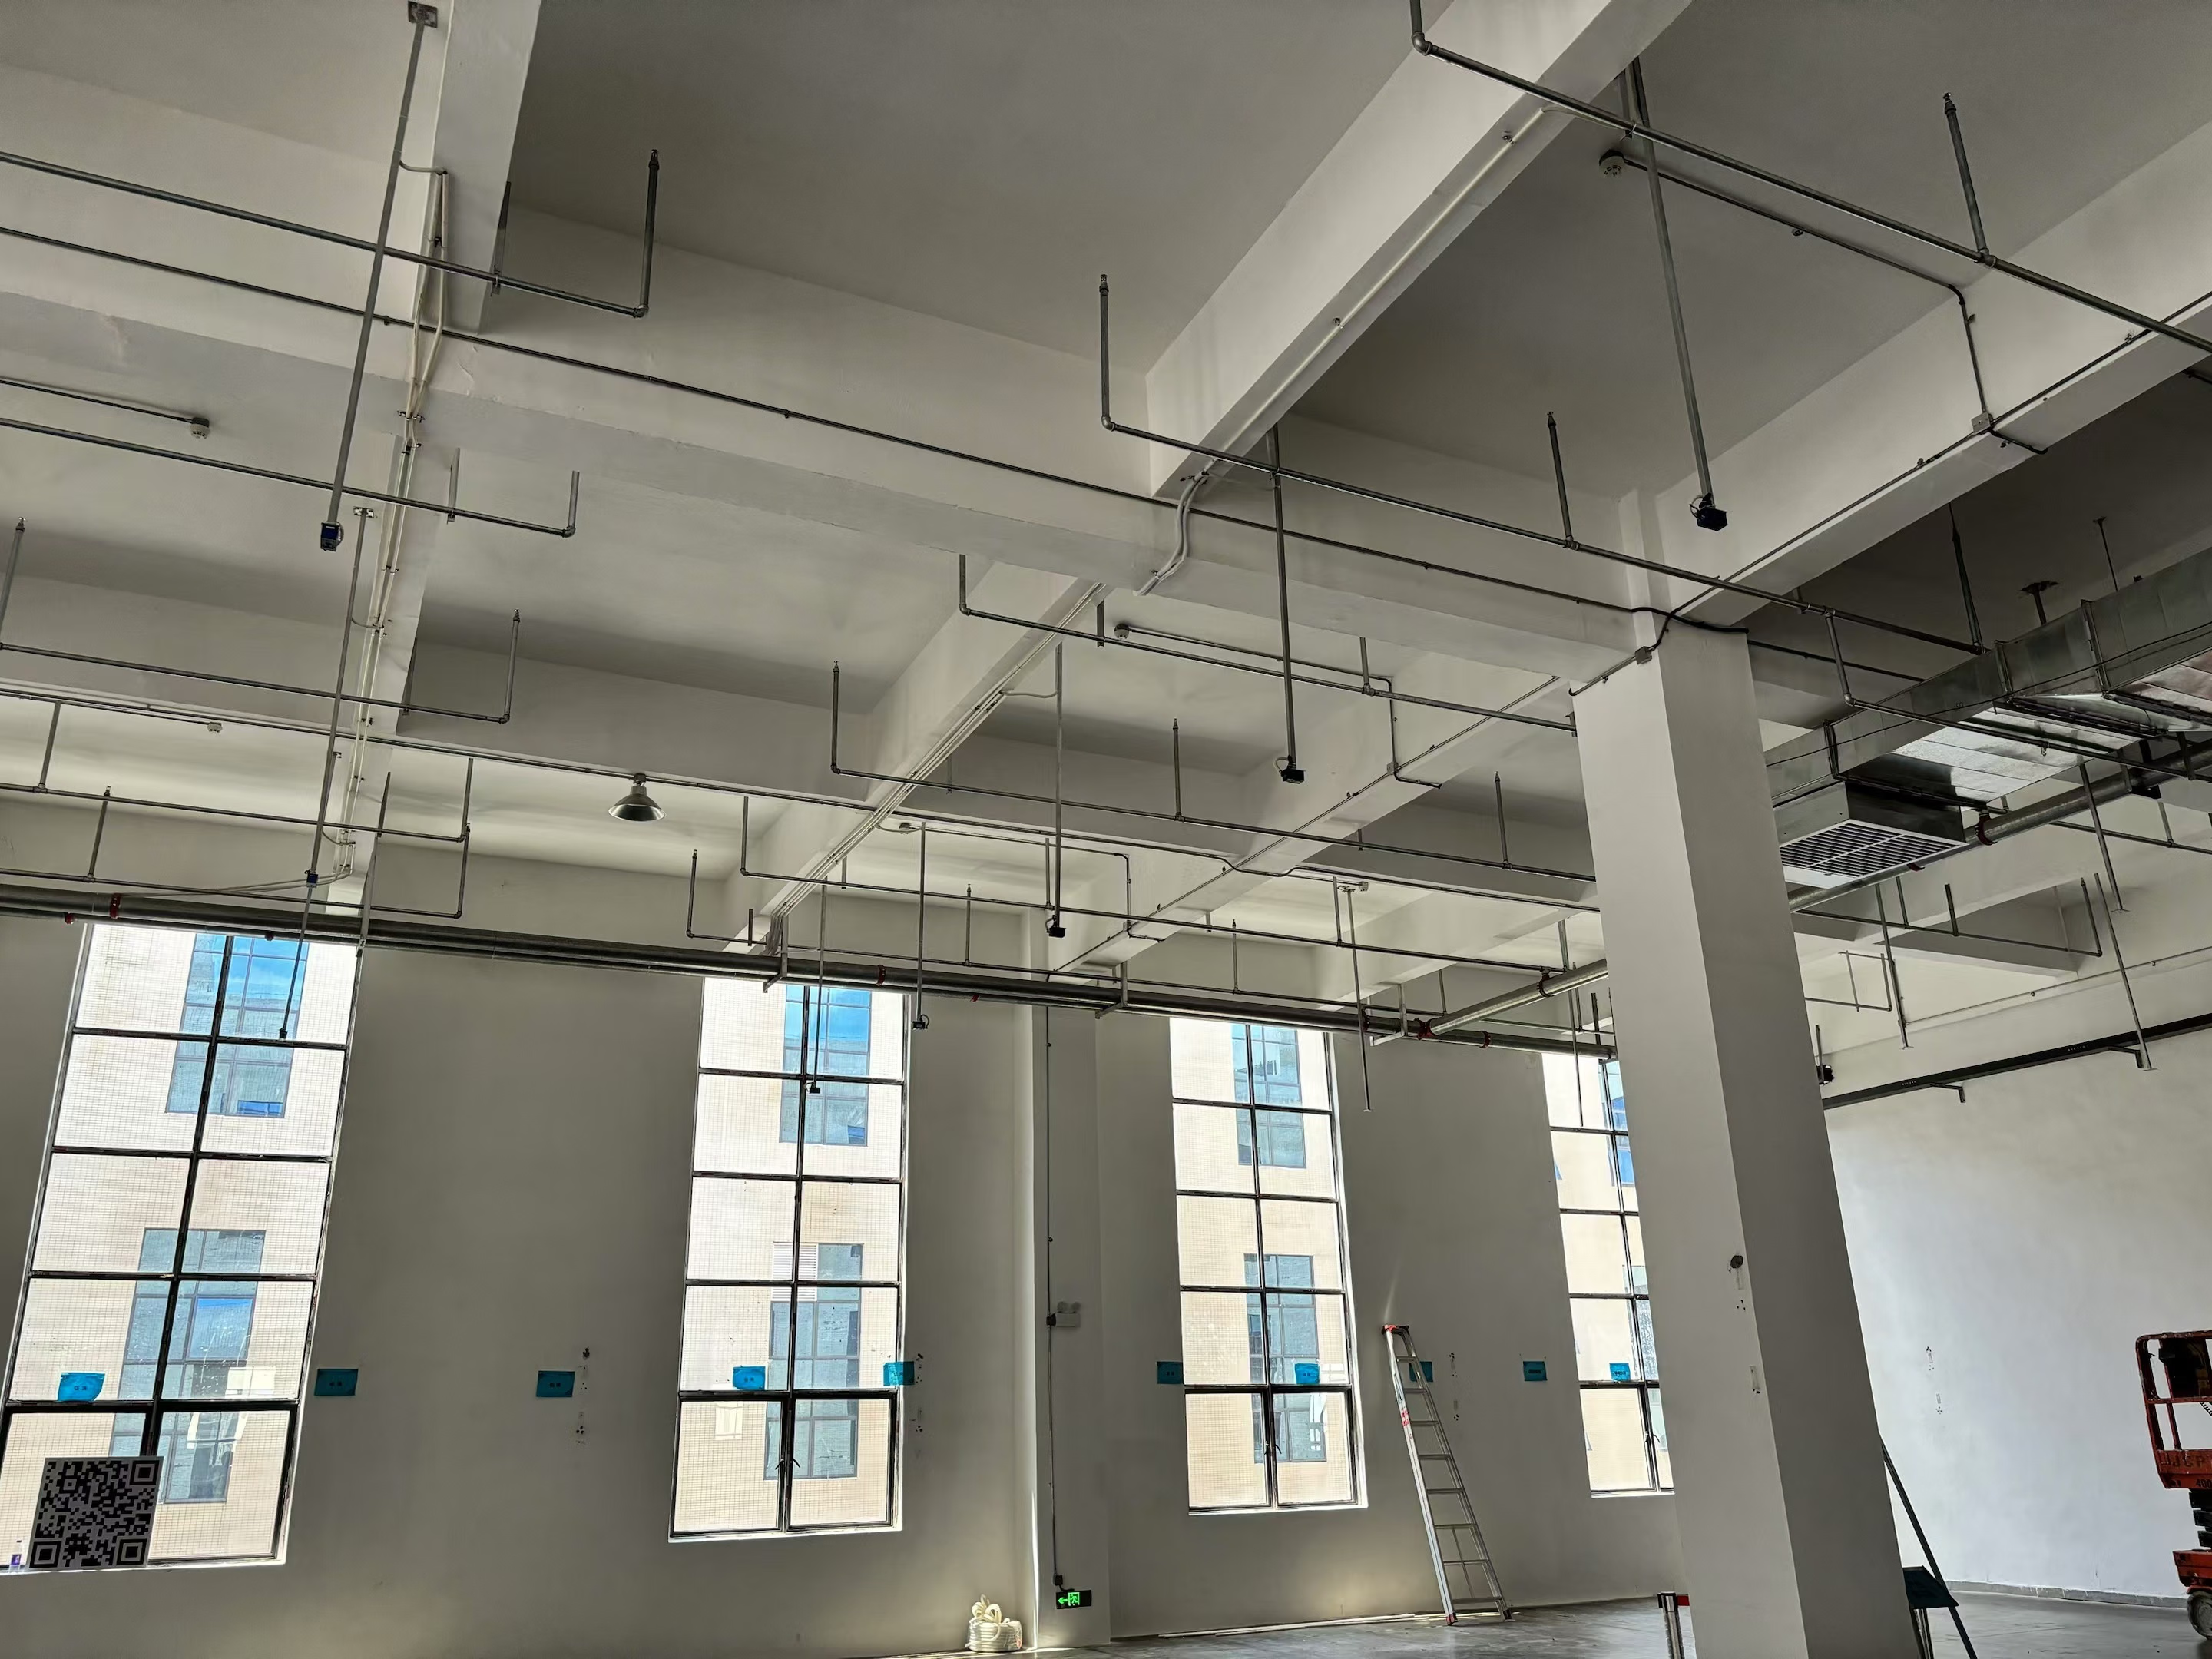
Project background
An automated warehouse in southern China uses multiple AGVs for material handling. Manual put-away and retrieval can leave the system’s recorded occupancy behind the actual site state, which may affect AGV pickup and placement tasks.
Solution selection
The project needed both location occupancy and load-height information. Single-point laser ranging can miss gaps between loads, while an RGB camera cannot directly provide height. The final solution uses an RGB-D camera to capture color, depth, and point-cloud data and runs the location-recognition algorithm on the camera.System implementation
- Capture 3D and color data from each location to identify occupancy and load height.
- Send results to the WMS or dispatch system in JSON over TCP/IP, UDP, or HTTP.
- Project records report more than one hundred sensors deployed for location-status monitoring.
On-site installation