
Project background
A chemical producer in Anhui previously relied on manual workers to depalletize and move soft packages. The packages deform easily and use different packaging materials, creating efficiency, dropped-package, and package-breakage risks.Solution
The project adopted a 3D vision soft-package depalletizing solution. An RGB-D camera captures package texture and 3D point-cloud data. The algorithm identifies package deformation and stack position, then provides the result to a robot arm for picking and transport to the unloading port.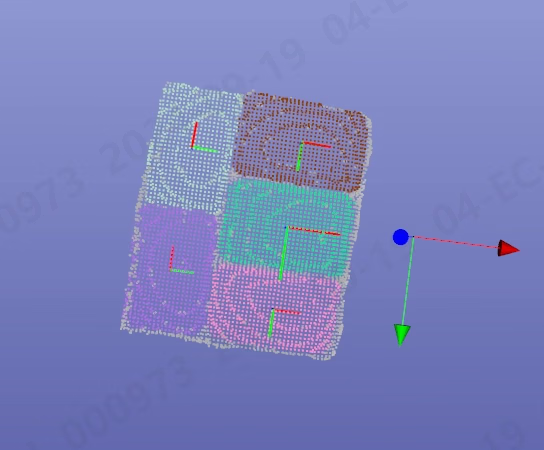
Implementation workflow
1
Recognize the package
The camera captures texture and point-cloud data and identifies the position and shape of the target package.
2
Plan the grasp
The system generates the robot-arm grasp sequence and provides target positions to the control system.
3
Move the package
The robot arm moves the package to the unloading port and hands it to the next process.